Designed and built a 6-axis robotic arm with embedded motion control, computer vision, inverse kinematics, network communication, and a real-time Unity digital twin.
Research and team engineering across AI, soft robotics, and competition robotics.
01
Research Intern
Computer Systems Lab · Yale University
Developed a Python AI agent for medical report generation using retrieval-augmented generation (RAG), semantic PDF parsing, preprocessing, and user-facing tools.
02
Research Assistant
C3RL · Purdue University
Developed and experimentally validated a variable-stiffness soft robotic finger through CAD, finite element modeling, TPU fabrication, and pressure-displacement testing.
03
FIRST Robotics Competition Team 461
Designed, prototyped, fabricated, and assembled competition intake mechanisms and swerve drivetrains through rapid build cycles using manual and CNC machining, laser cutting, FDM printing, power tools, and general shop tools.
03
ABOUT
Curious about how things move.
Mechanical engineering student focused on robotics, controls, computer vision, and physical systems.
At Columbia Engineering, I develop systems through fabrication, measurement, and hardware testing.
Outside engineering, I swim, train Sanda, cook Italian food, play Black Myth: Wukong, and design and resin-print miniatures.
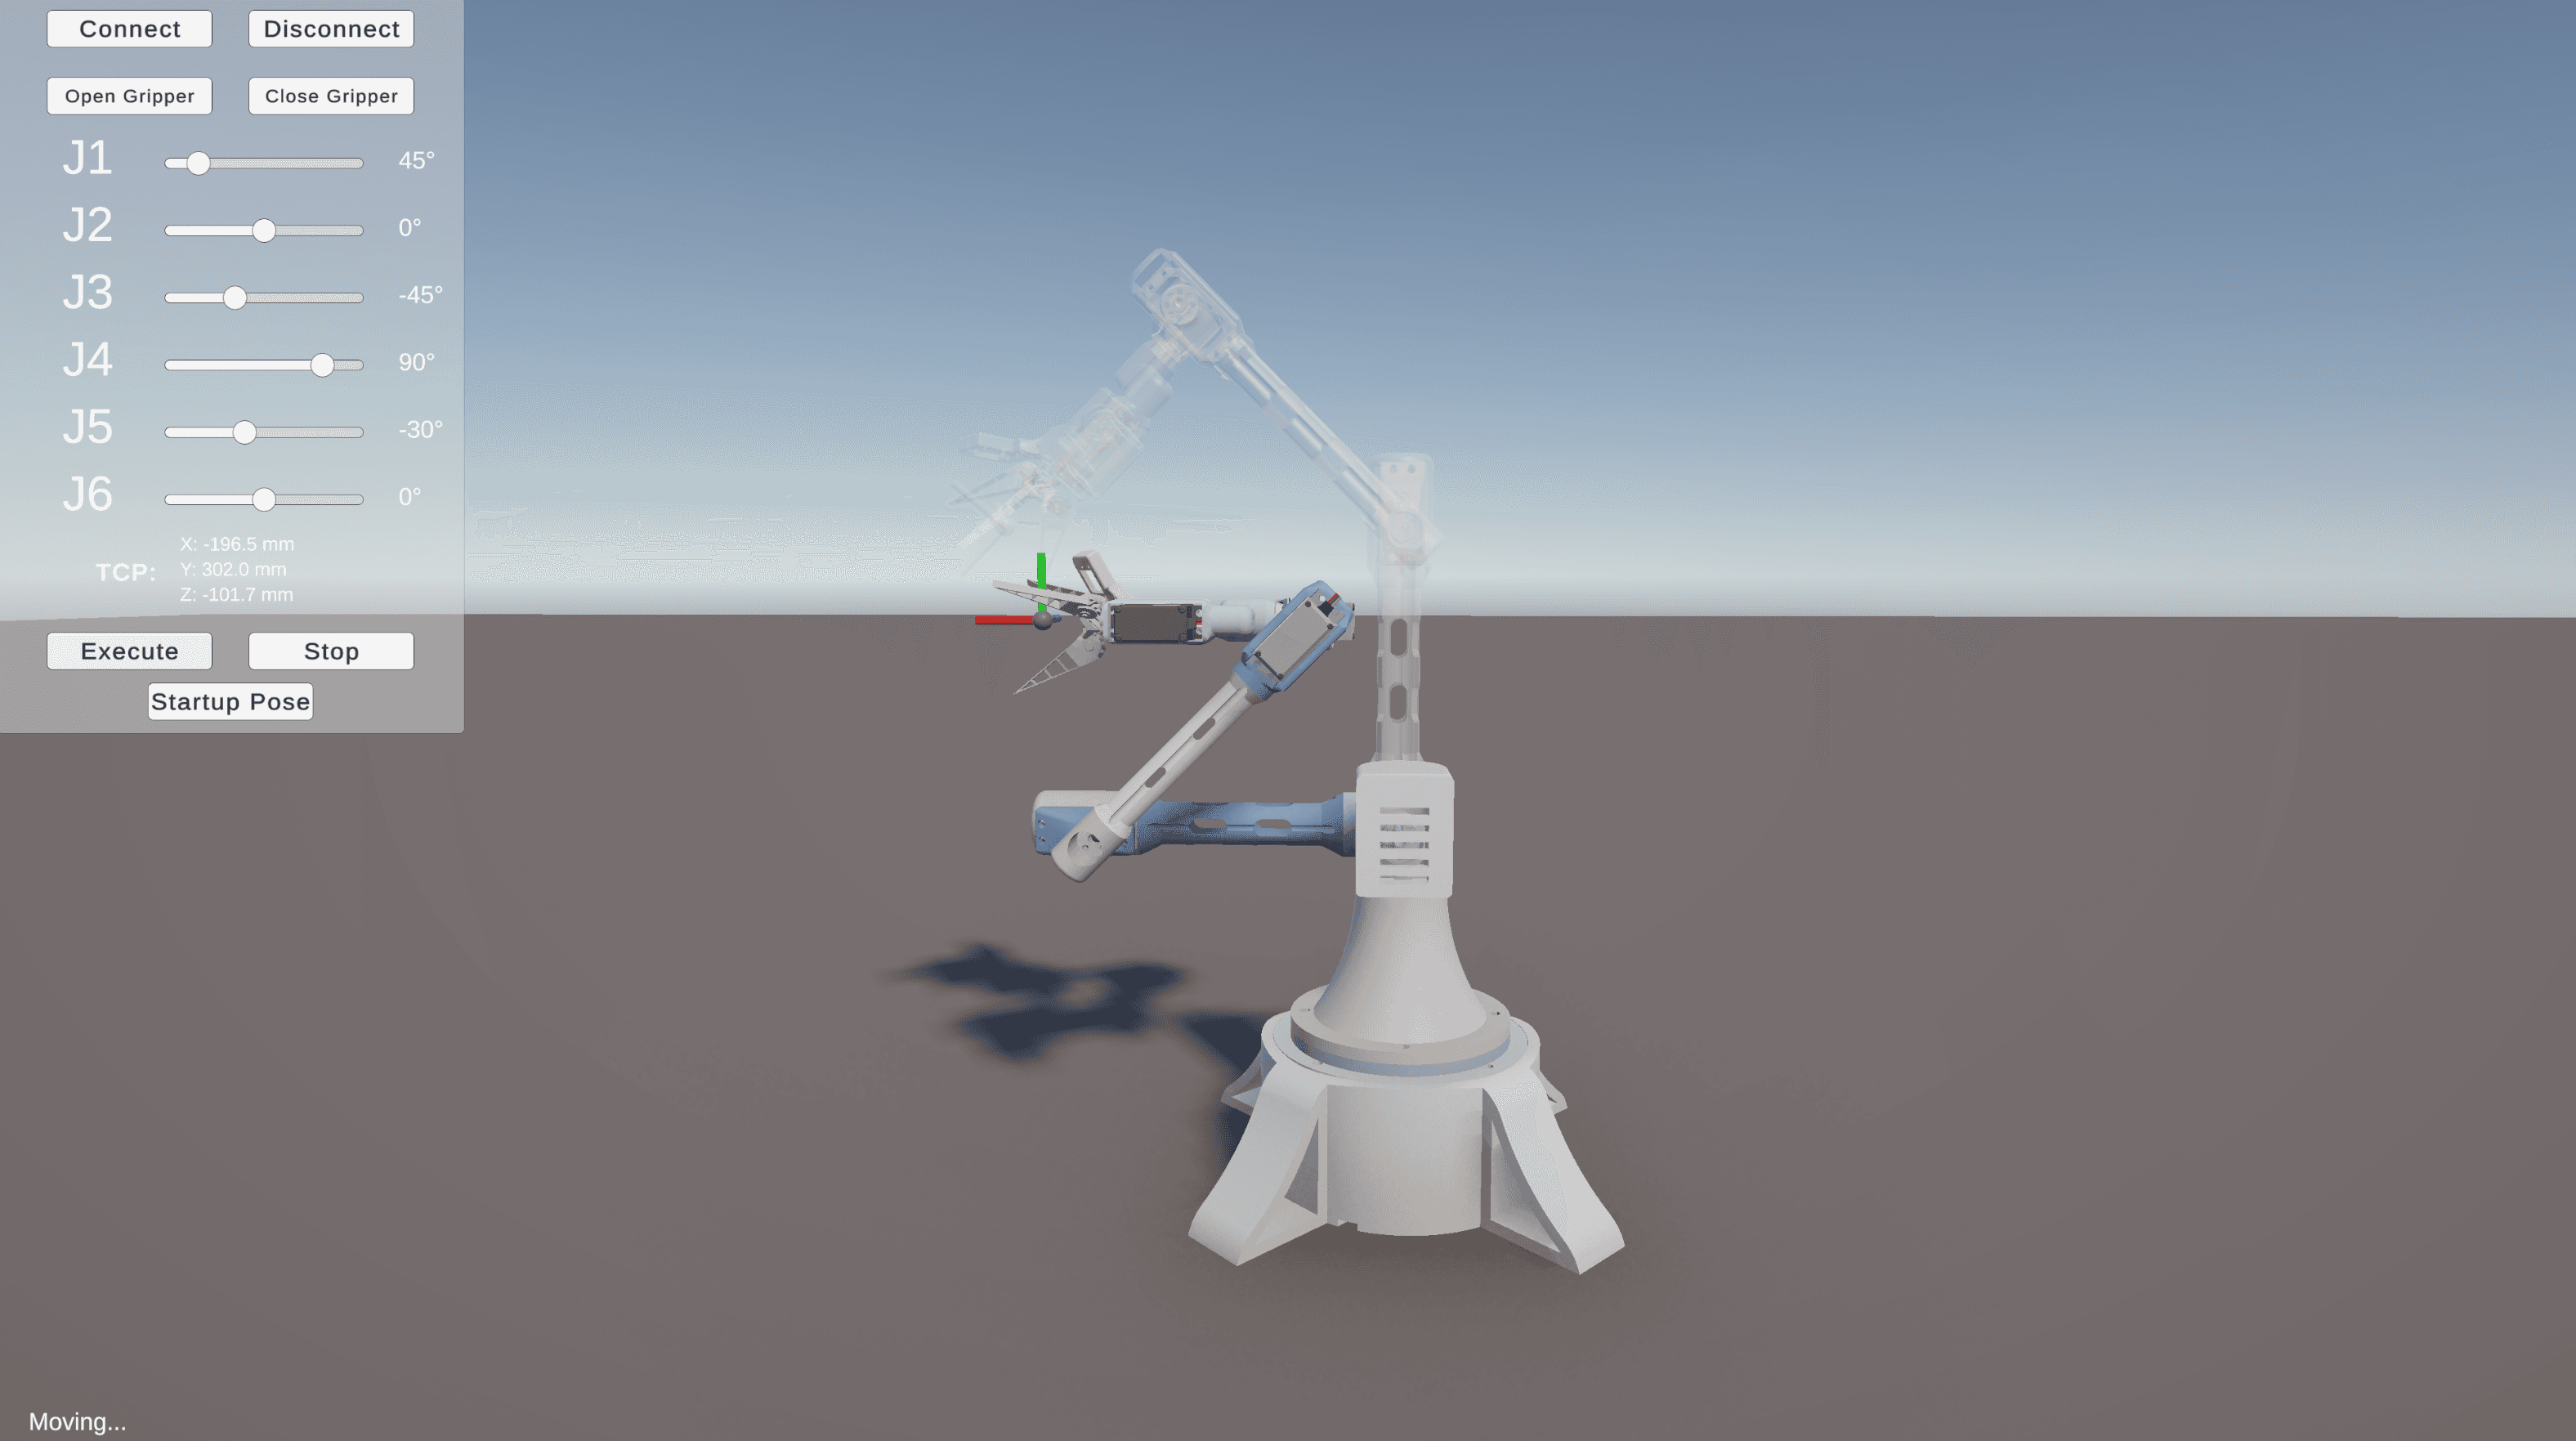 Unity Digital Twin