6-DOF Robotic Arm + Digital Twin
Designed and built a 6-axis robotic arm with embedded motion control, computer vision, inverse kinematics, network communication, and a real-time Unity digital twin.
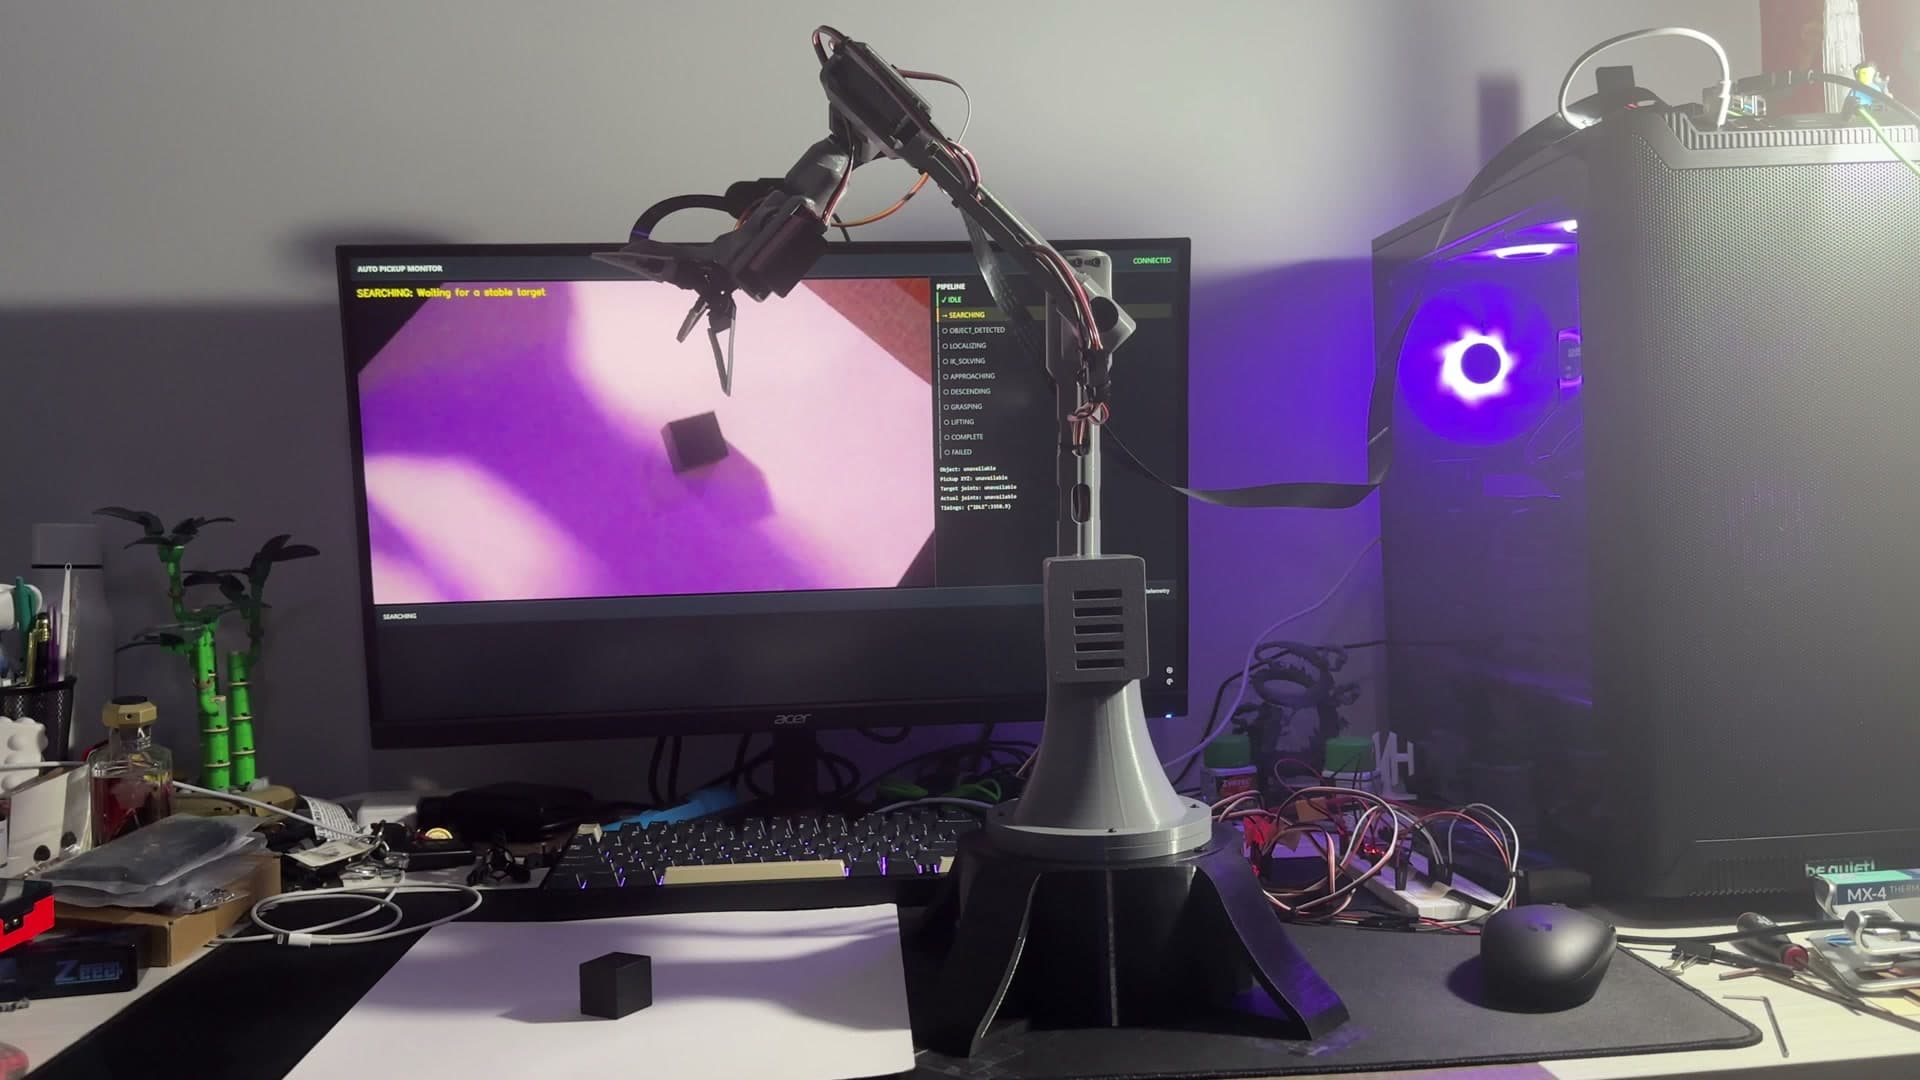
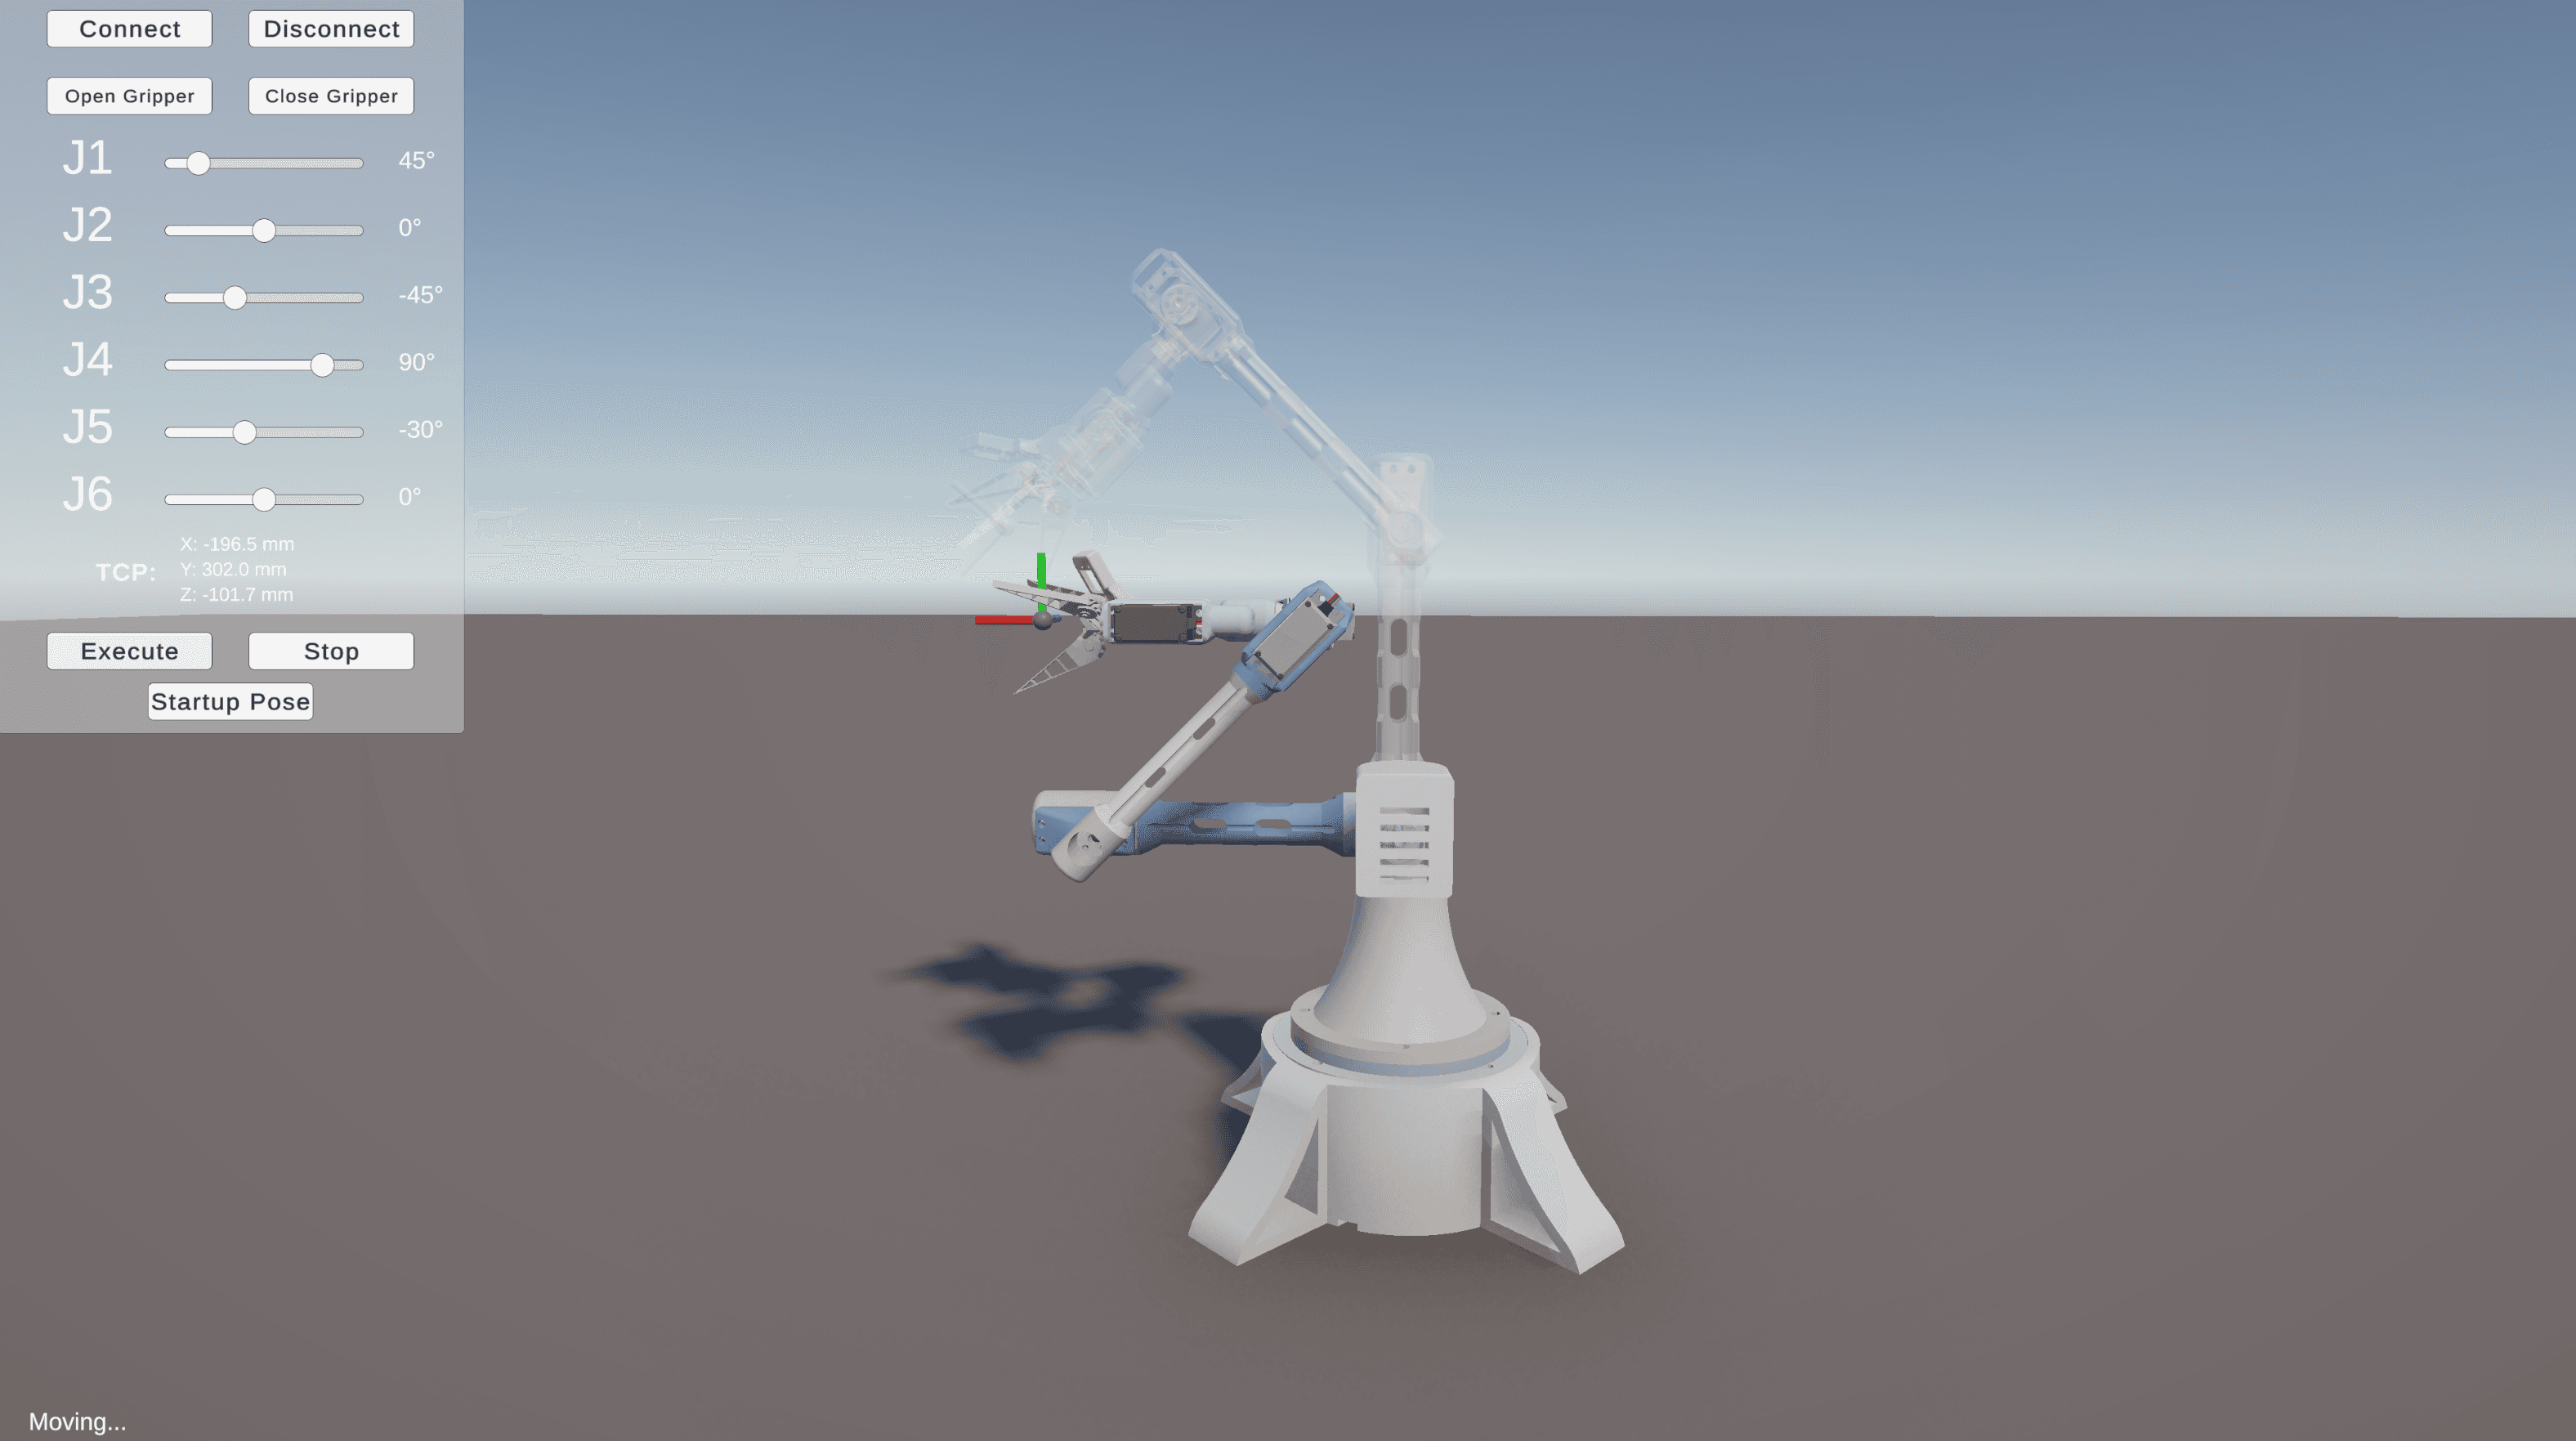
One control stack connects the physical arm and digital twin.
A Raspberry Pi handles planning and vision, an ESP32 controls motion through a PCA9685 servo driver, and Unity visualizes live state, target poses, and predicted trajectories.
From digital intent to physical motion.
The architecture separates visualization, perception, control, and actuation while keeping robot state connected across the system.
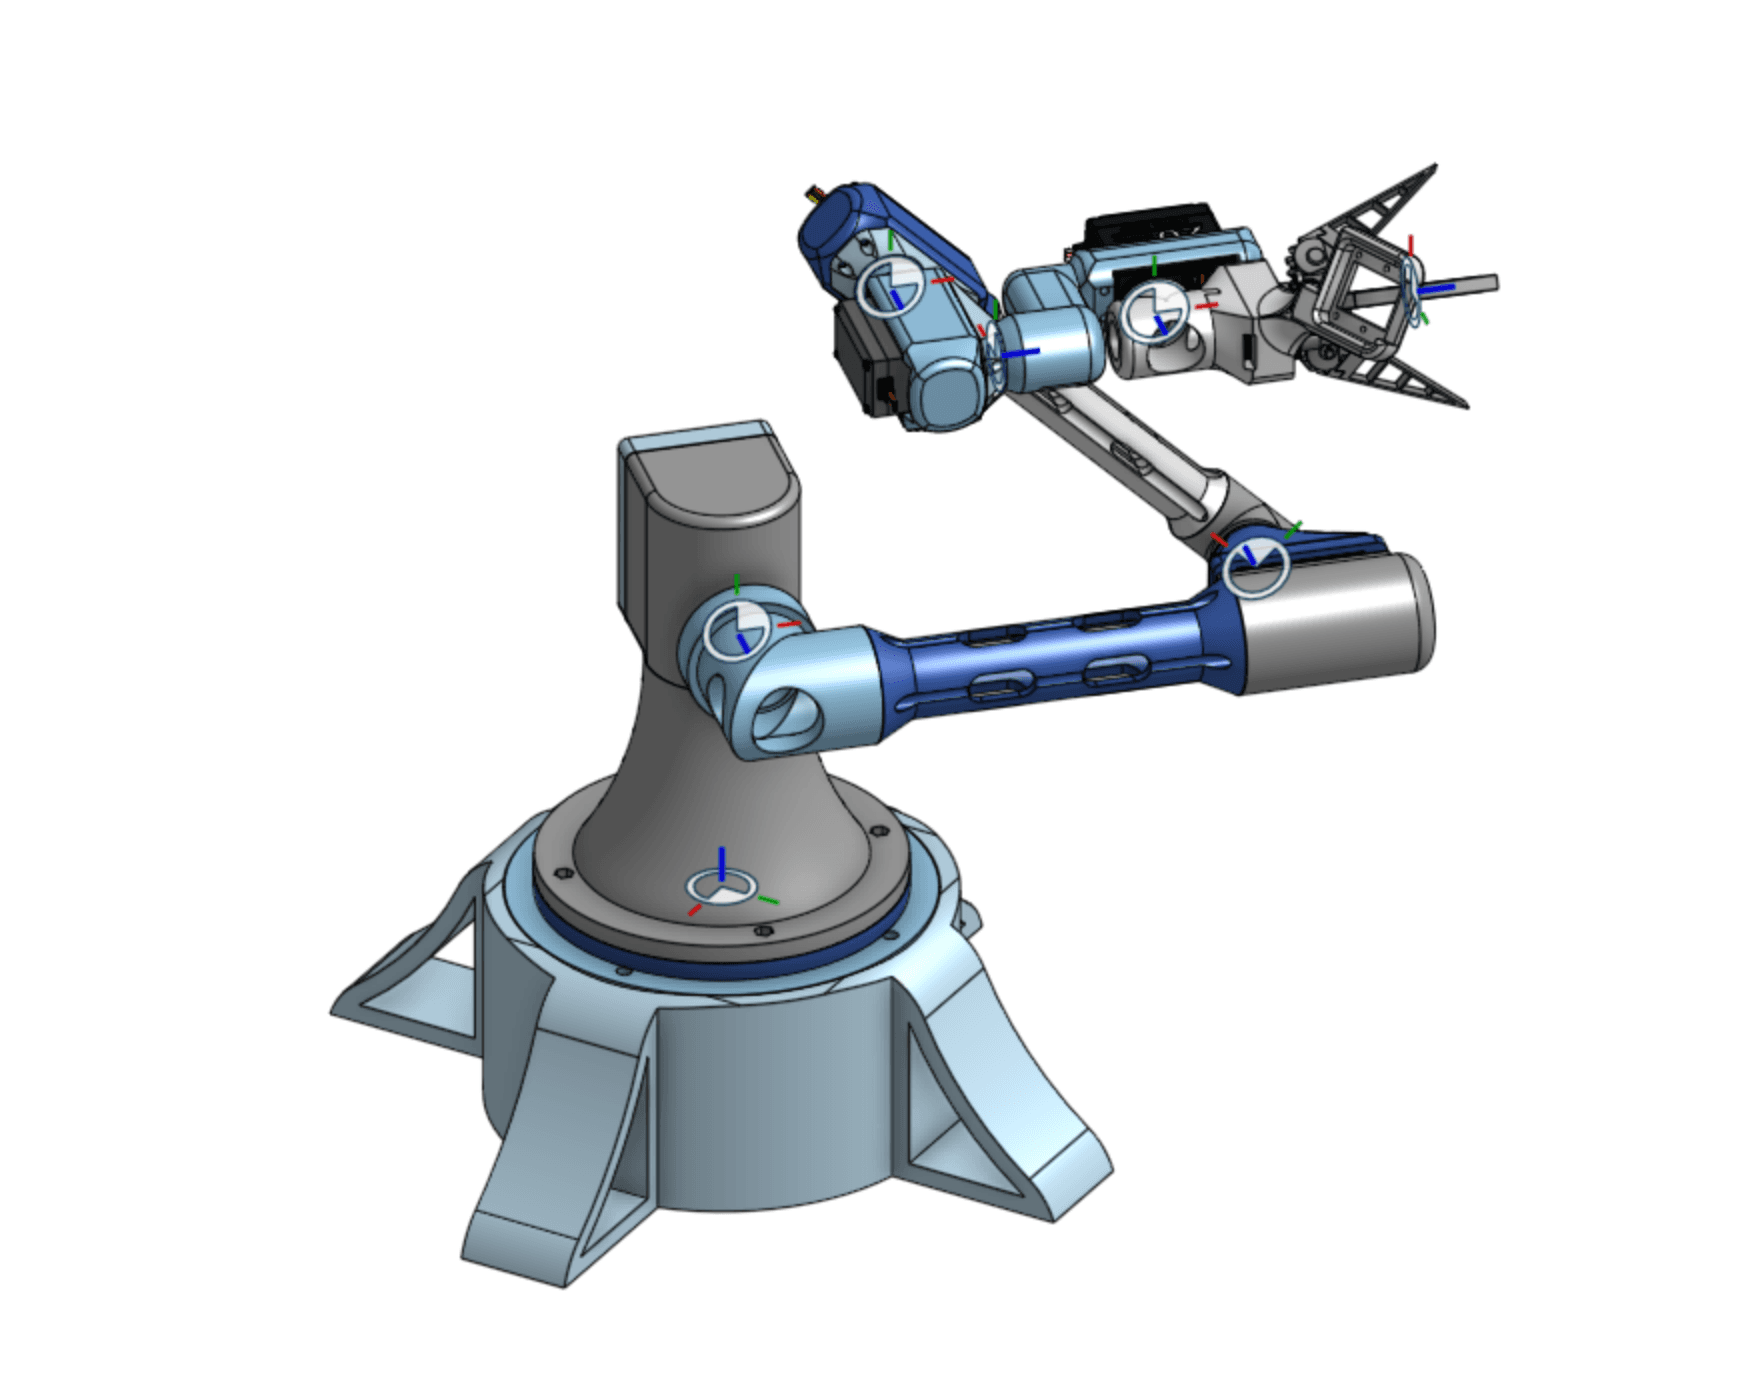
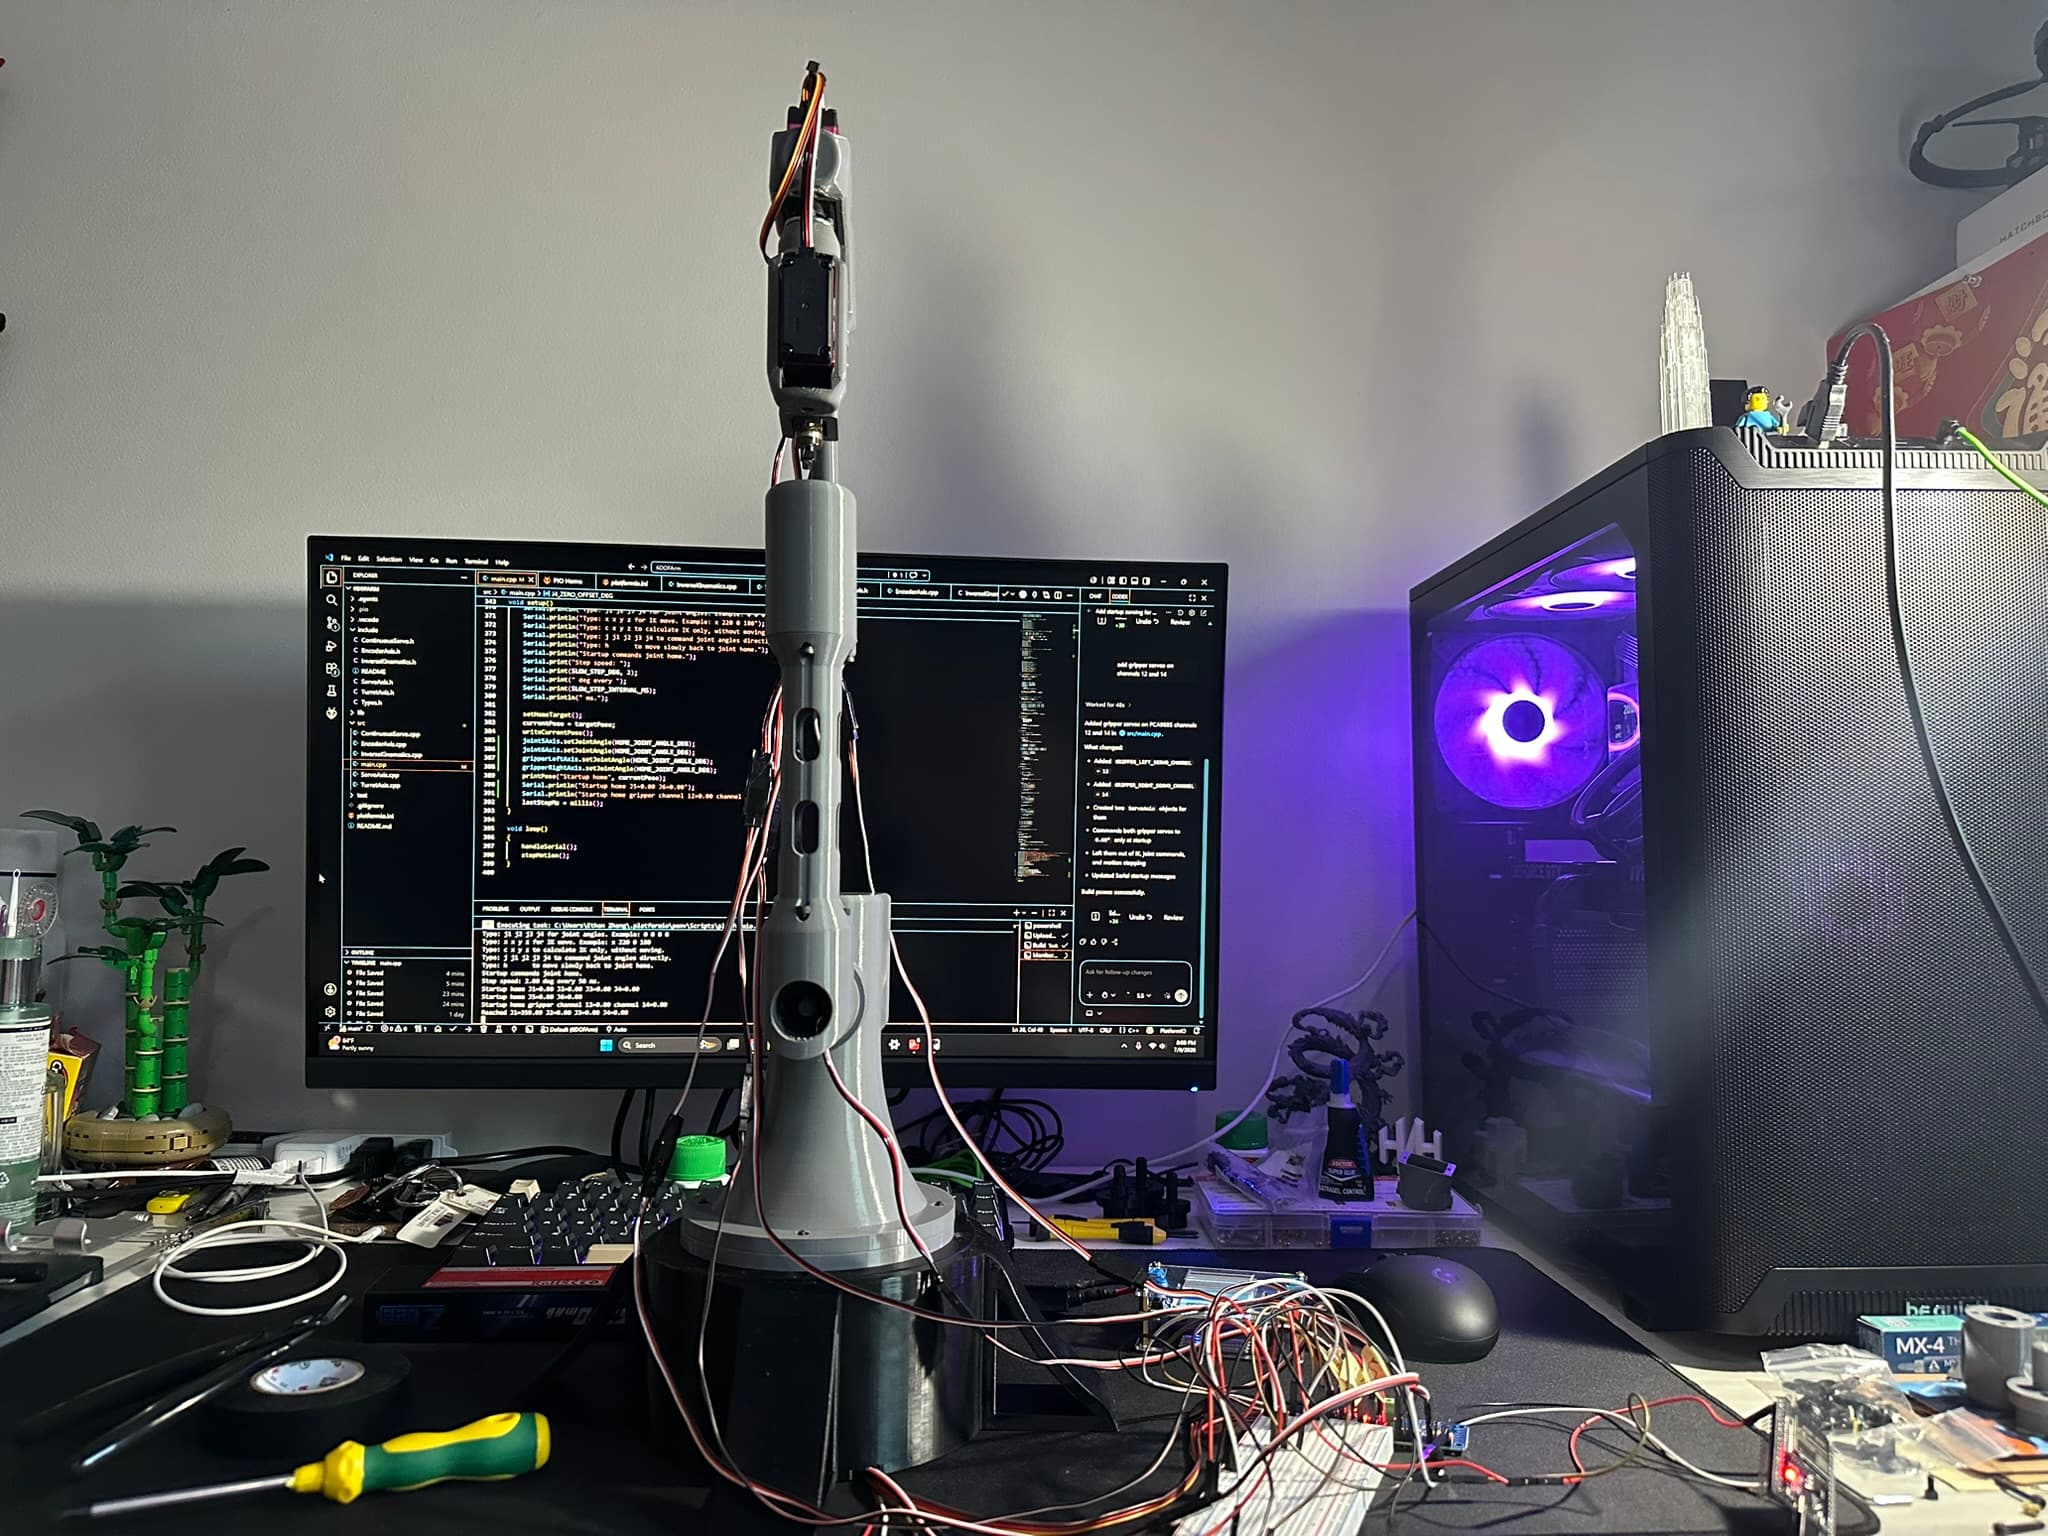
Six-axis modular assembly.
ACTUATORS
- J1
- Base
TD-8135MG- J2
- Shoulder
DS3240- J3
- Elbow
DS3240- J4
- Wrist
DS3225- J5
- Wrist
DS3218- J6
- Wrist
DS3218- GRIP
- Gripper
MG90D
Servo-driven joints connect 3D-printed PETG structures with an integrated gripper and camera mount.
Joint and end-effector development.
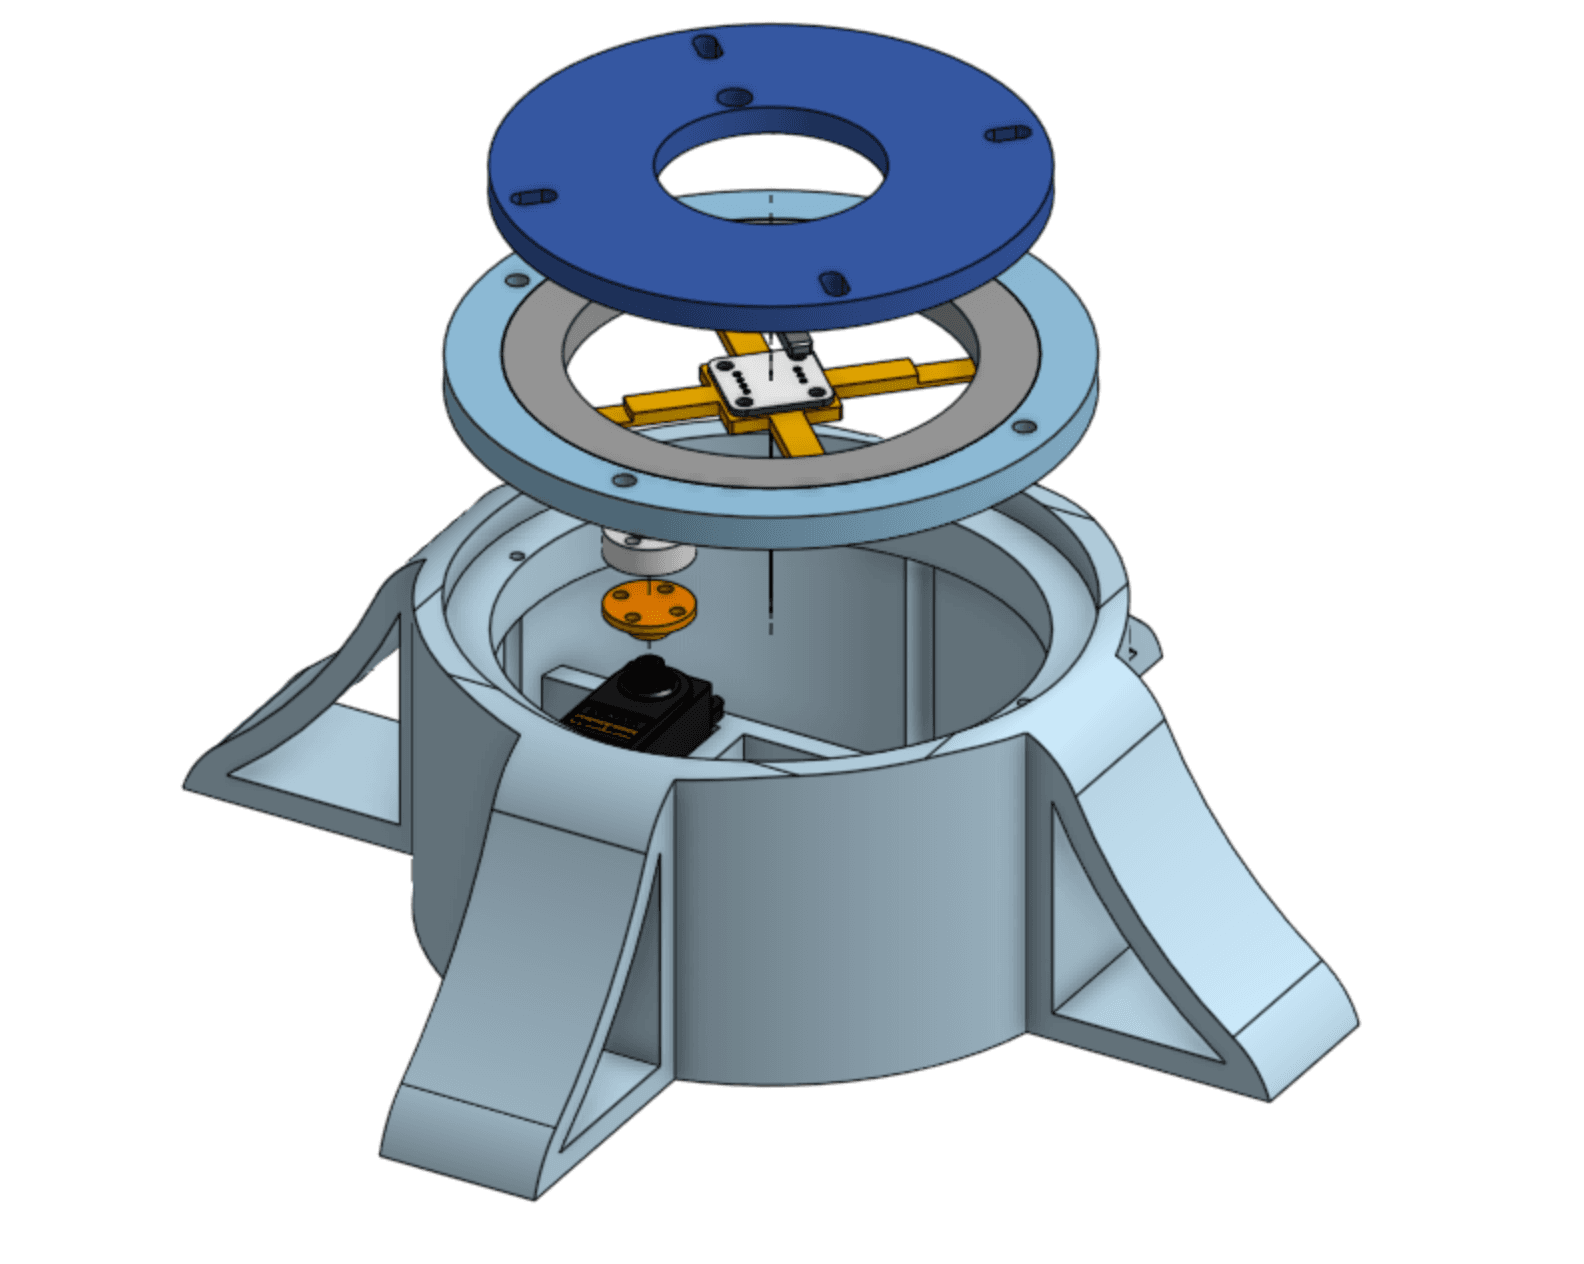
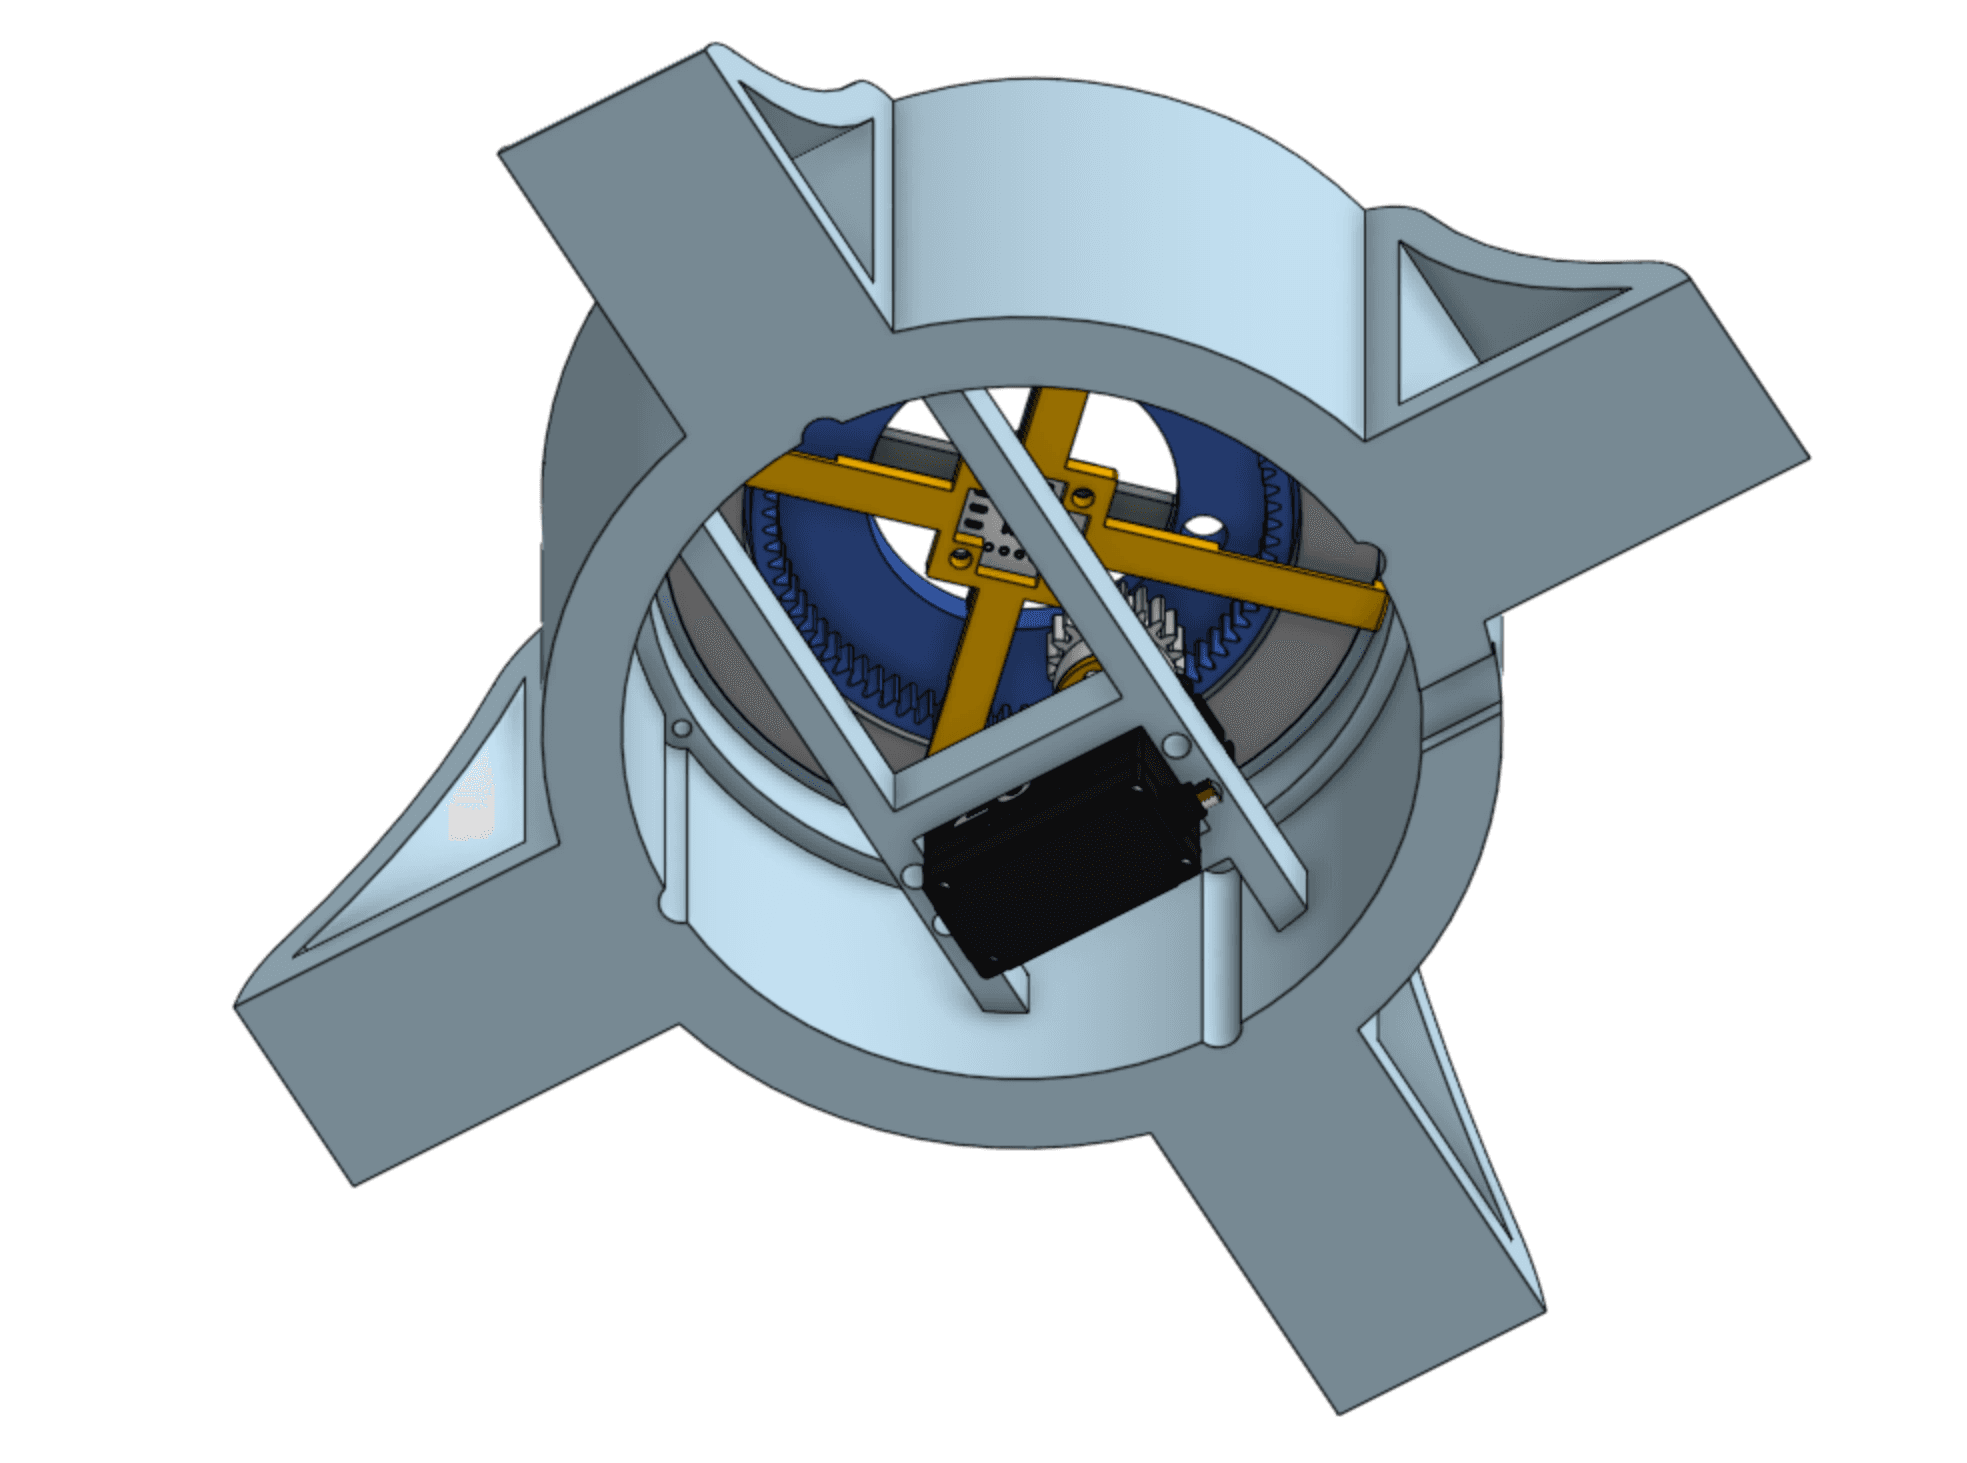
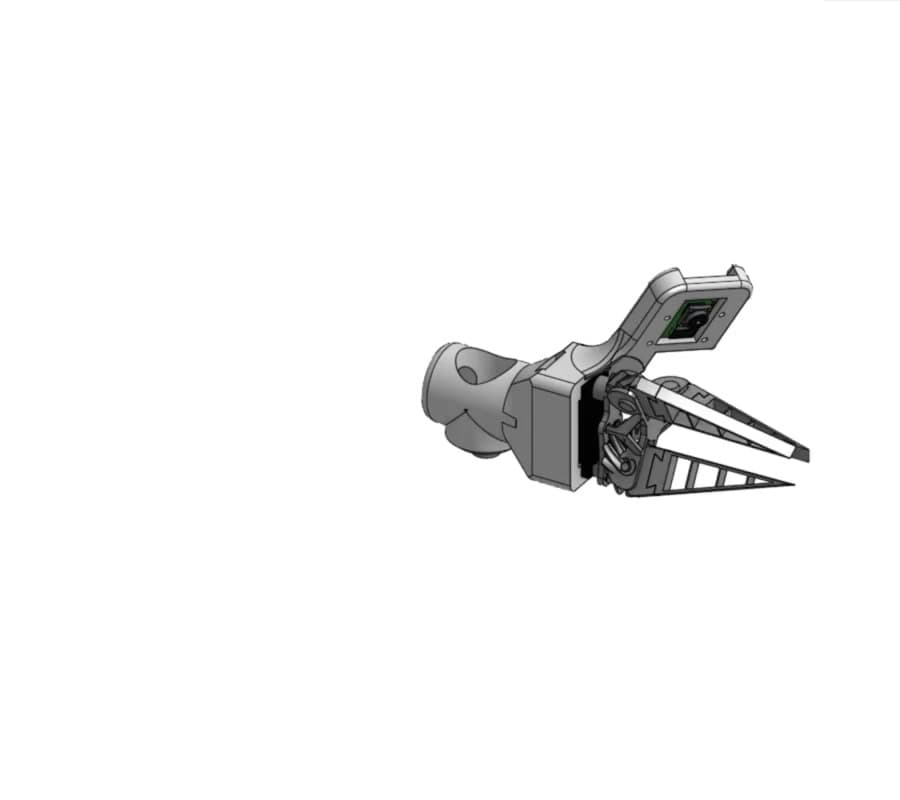
Designed the joint interfaces and end effector around the selected servos, with an eye-in-hand camera mounted above the gripper for object detection.
Custom-trained cube detection, deployed on the robot.
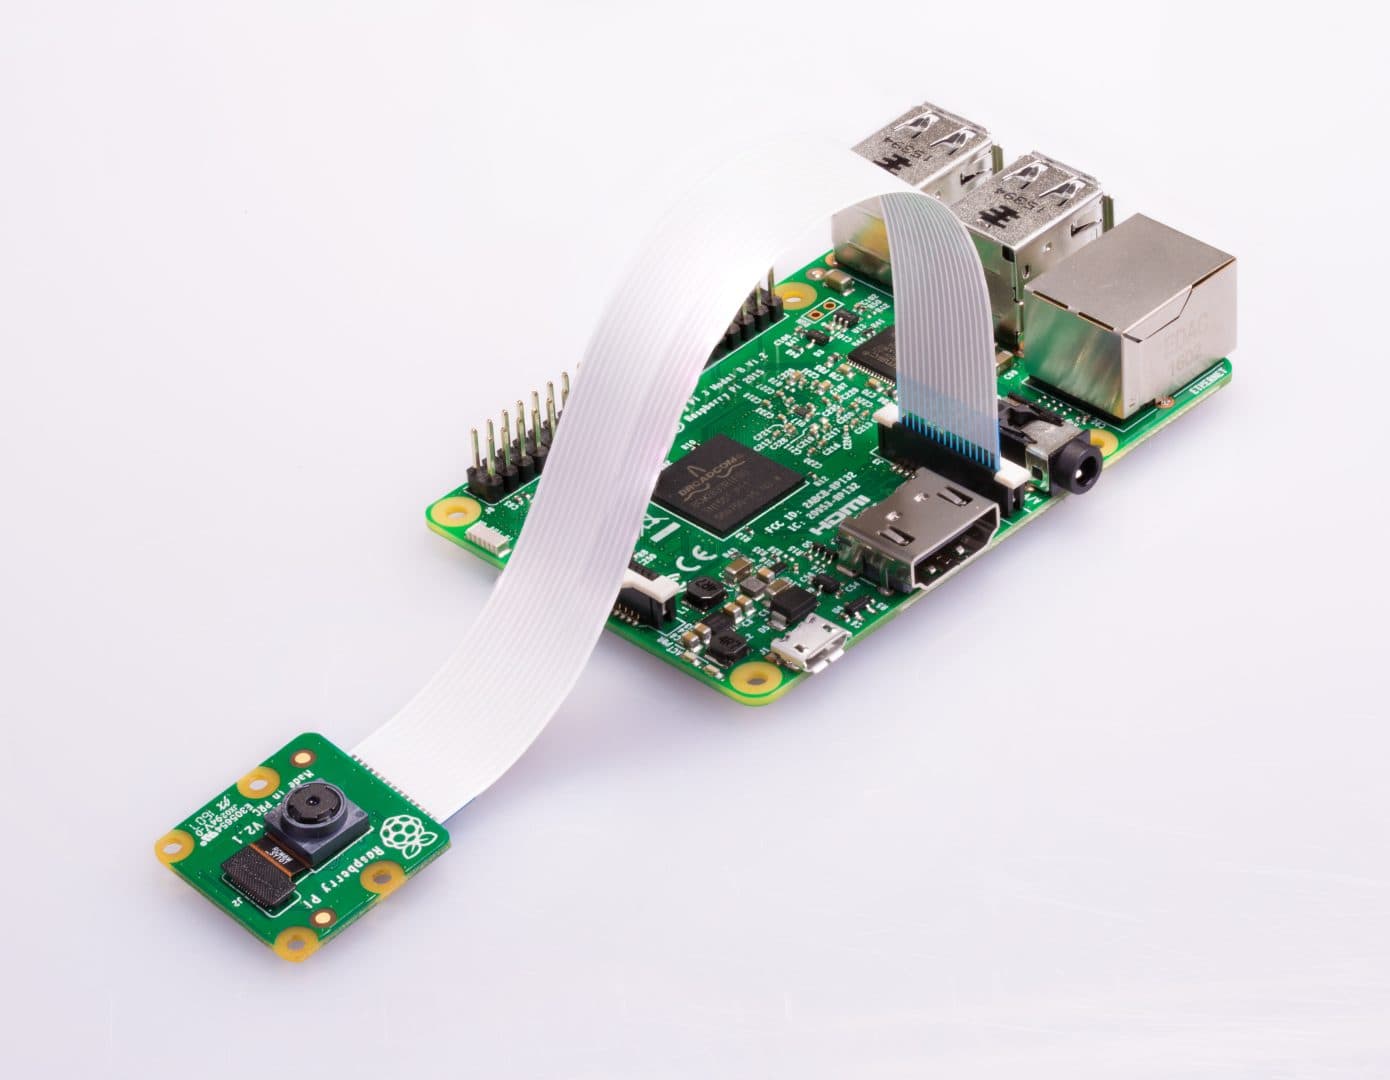
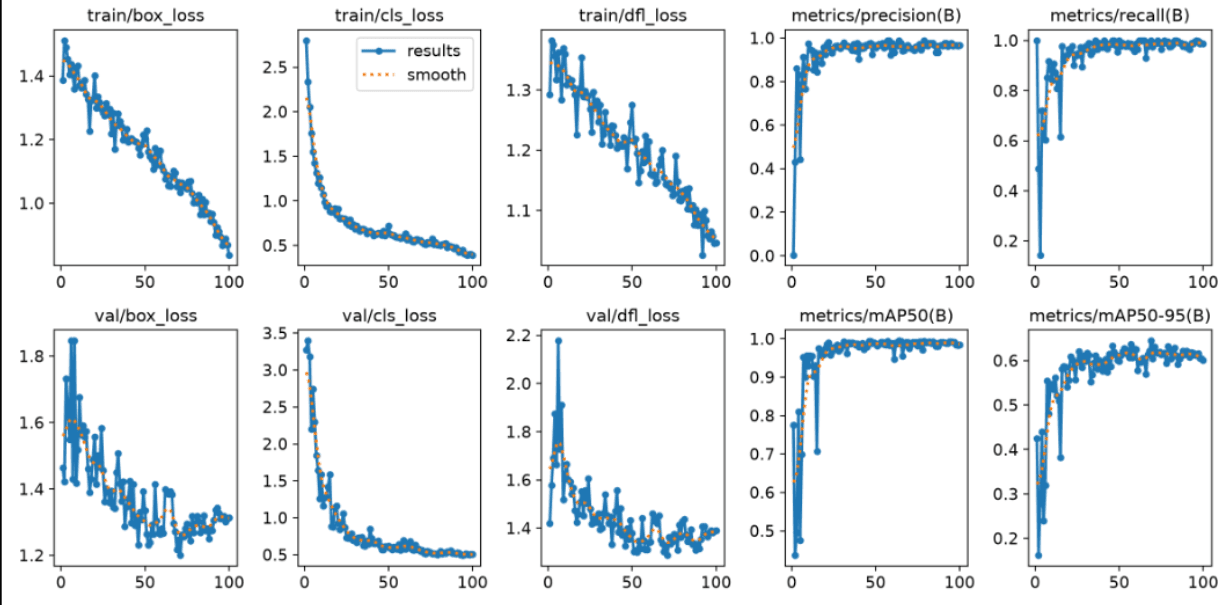
Trained a YOLO11n cube detector for 100 epochs on a custom 500-image dataset and exported it to NCNN for inference on a Raspberry Pi 4 with Camera Module v2.
Connecting image coordinates to the robot workspace.
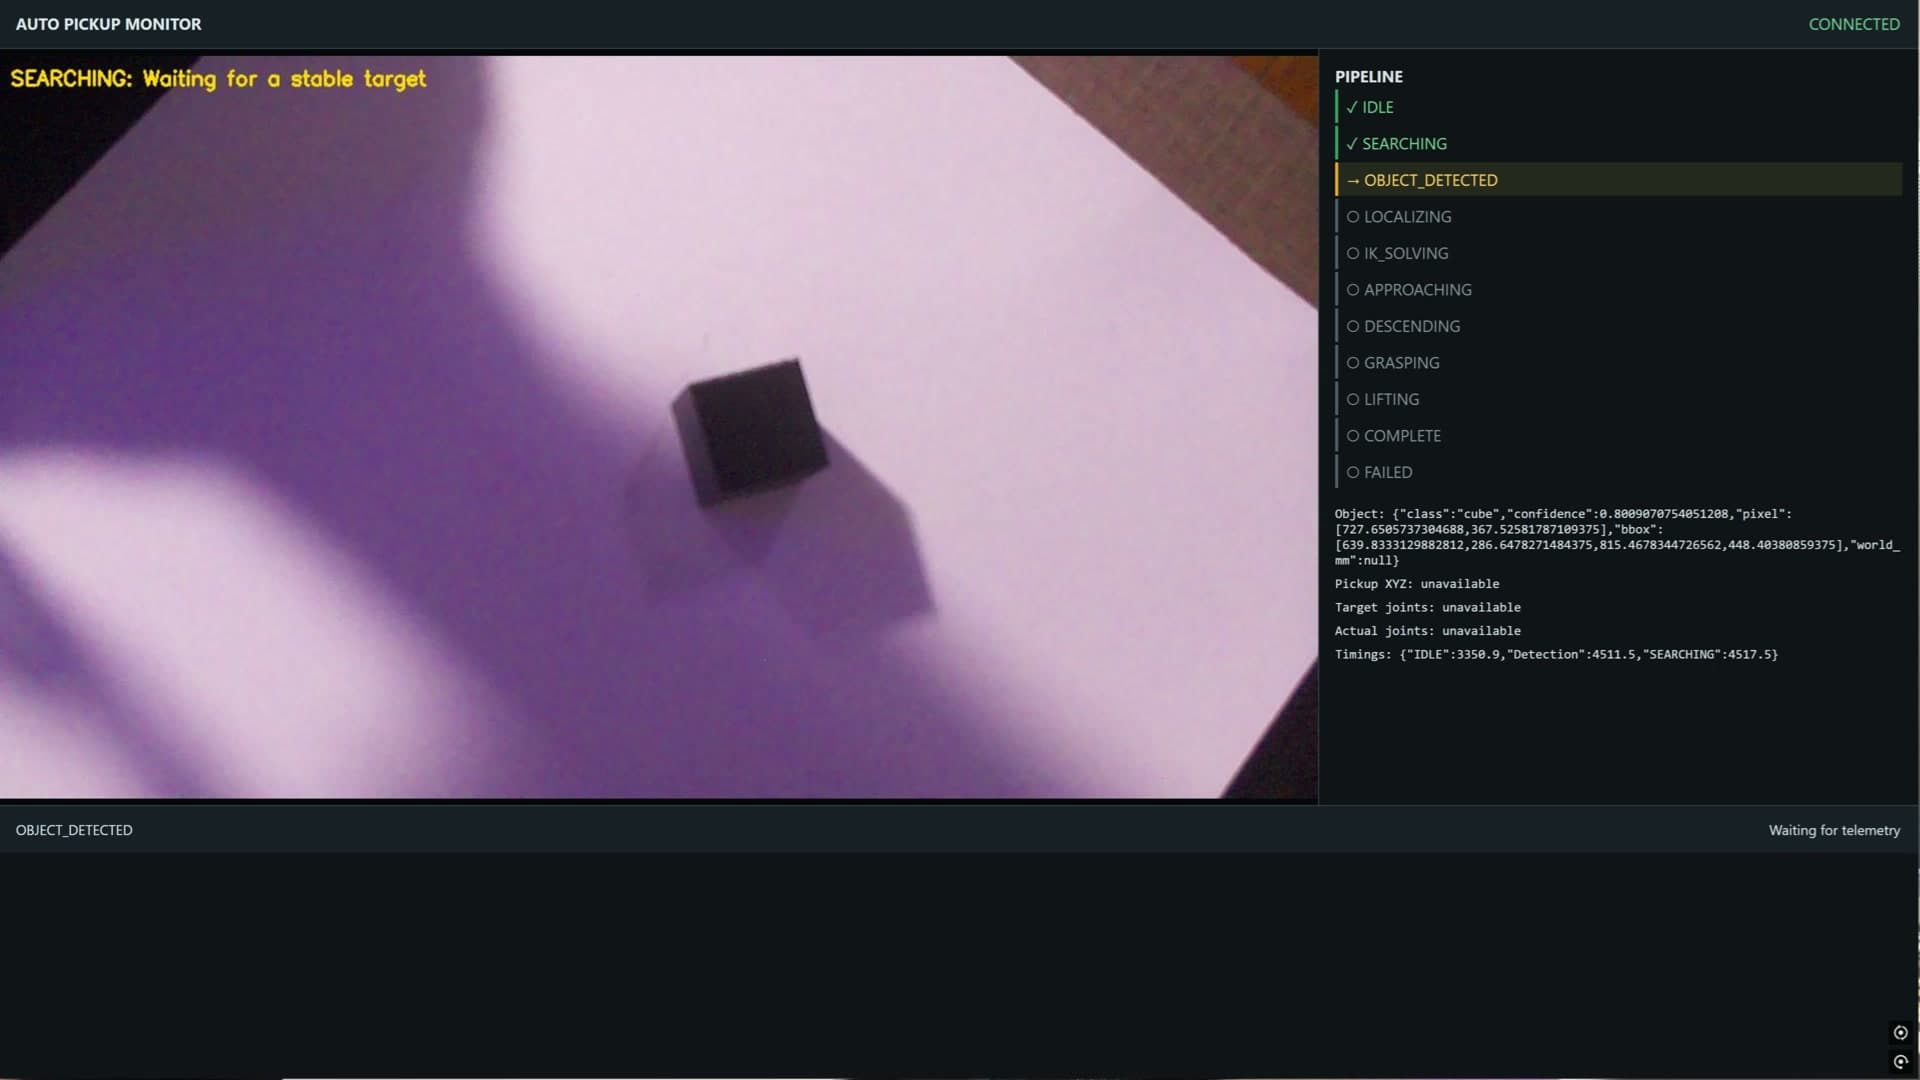
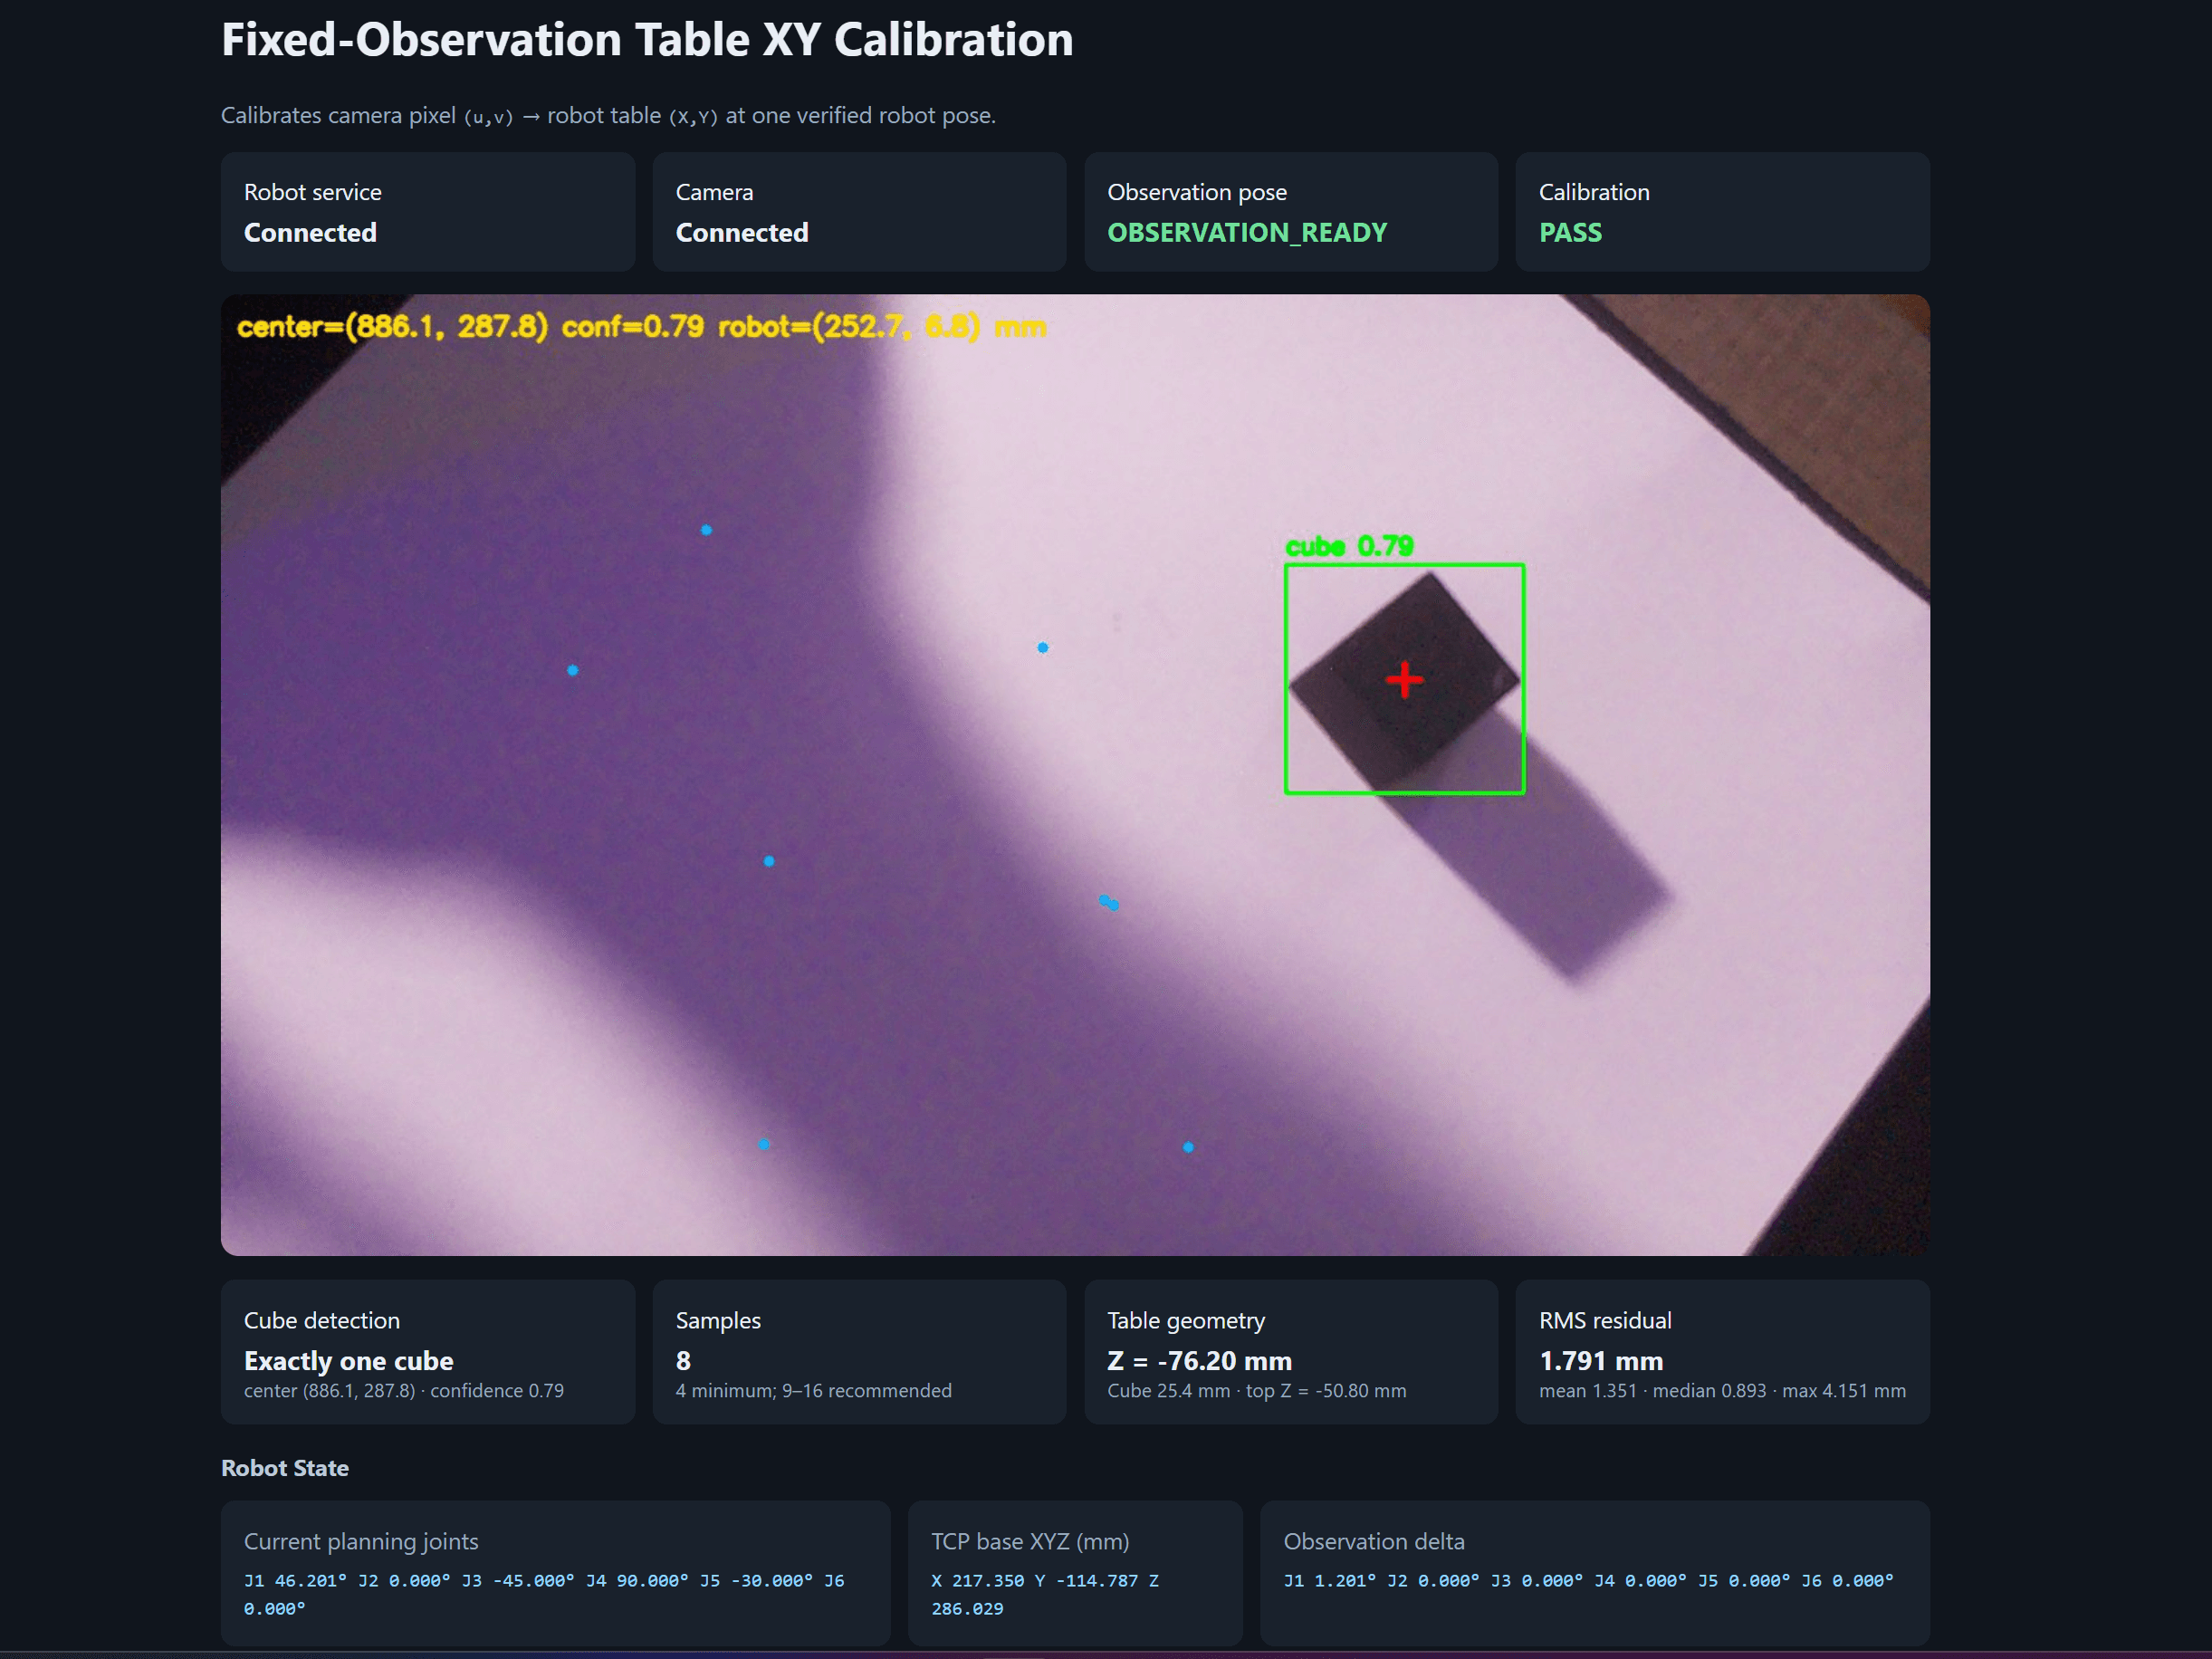
At a fixed observation pose, an XY homography maps detected cube locations from camera pixels to robot-table coordinates for motion planning.
Live state, previewed motion, and physical synchronization.
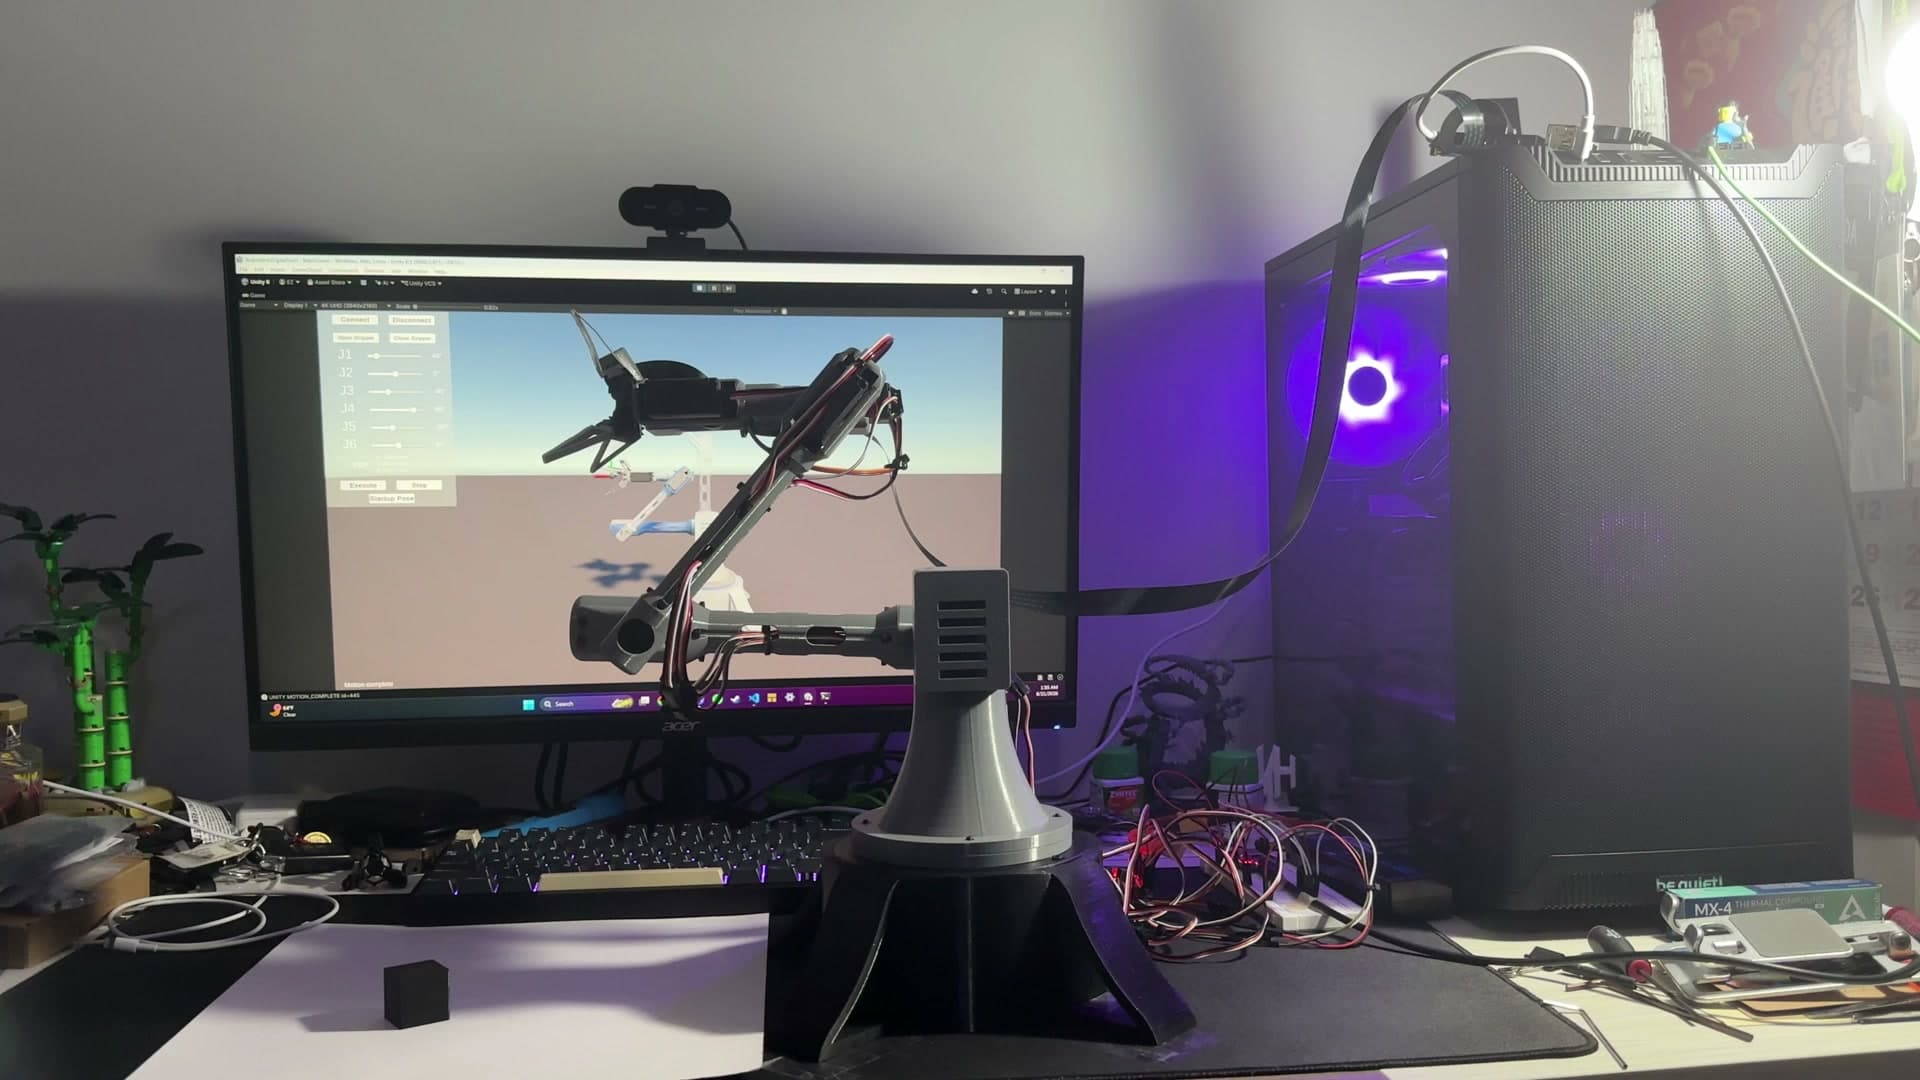
Built a Unity digital twin for live robot-state visualization, ghost-pose target preview, and trajectory prediction synchronized with the physical arm.