← All projects
PROJECT / 05MECHATRONICS / VEHICLE DESIGN / CONTROLS

Electric Vehicle

Built a Science Olympiad electric vehicle using encoder feedback and stopping-distance compensation to stop at a specified distance.
Arduino UnoEncoder FeedbackMotor ControlMechanical DesignDrivetrainTesting
HERO / 01Target-Distance Run
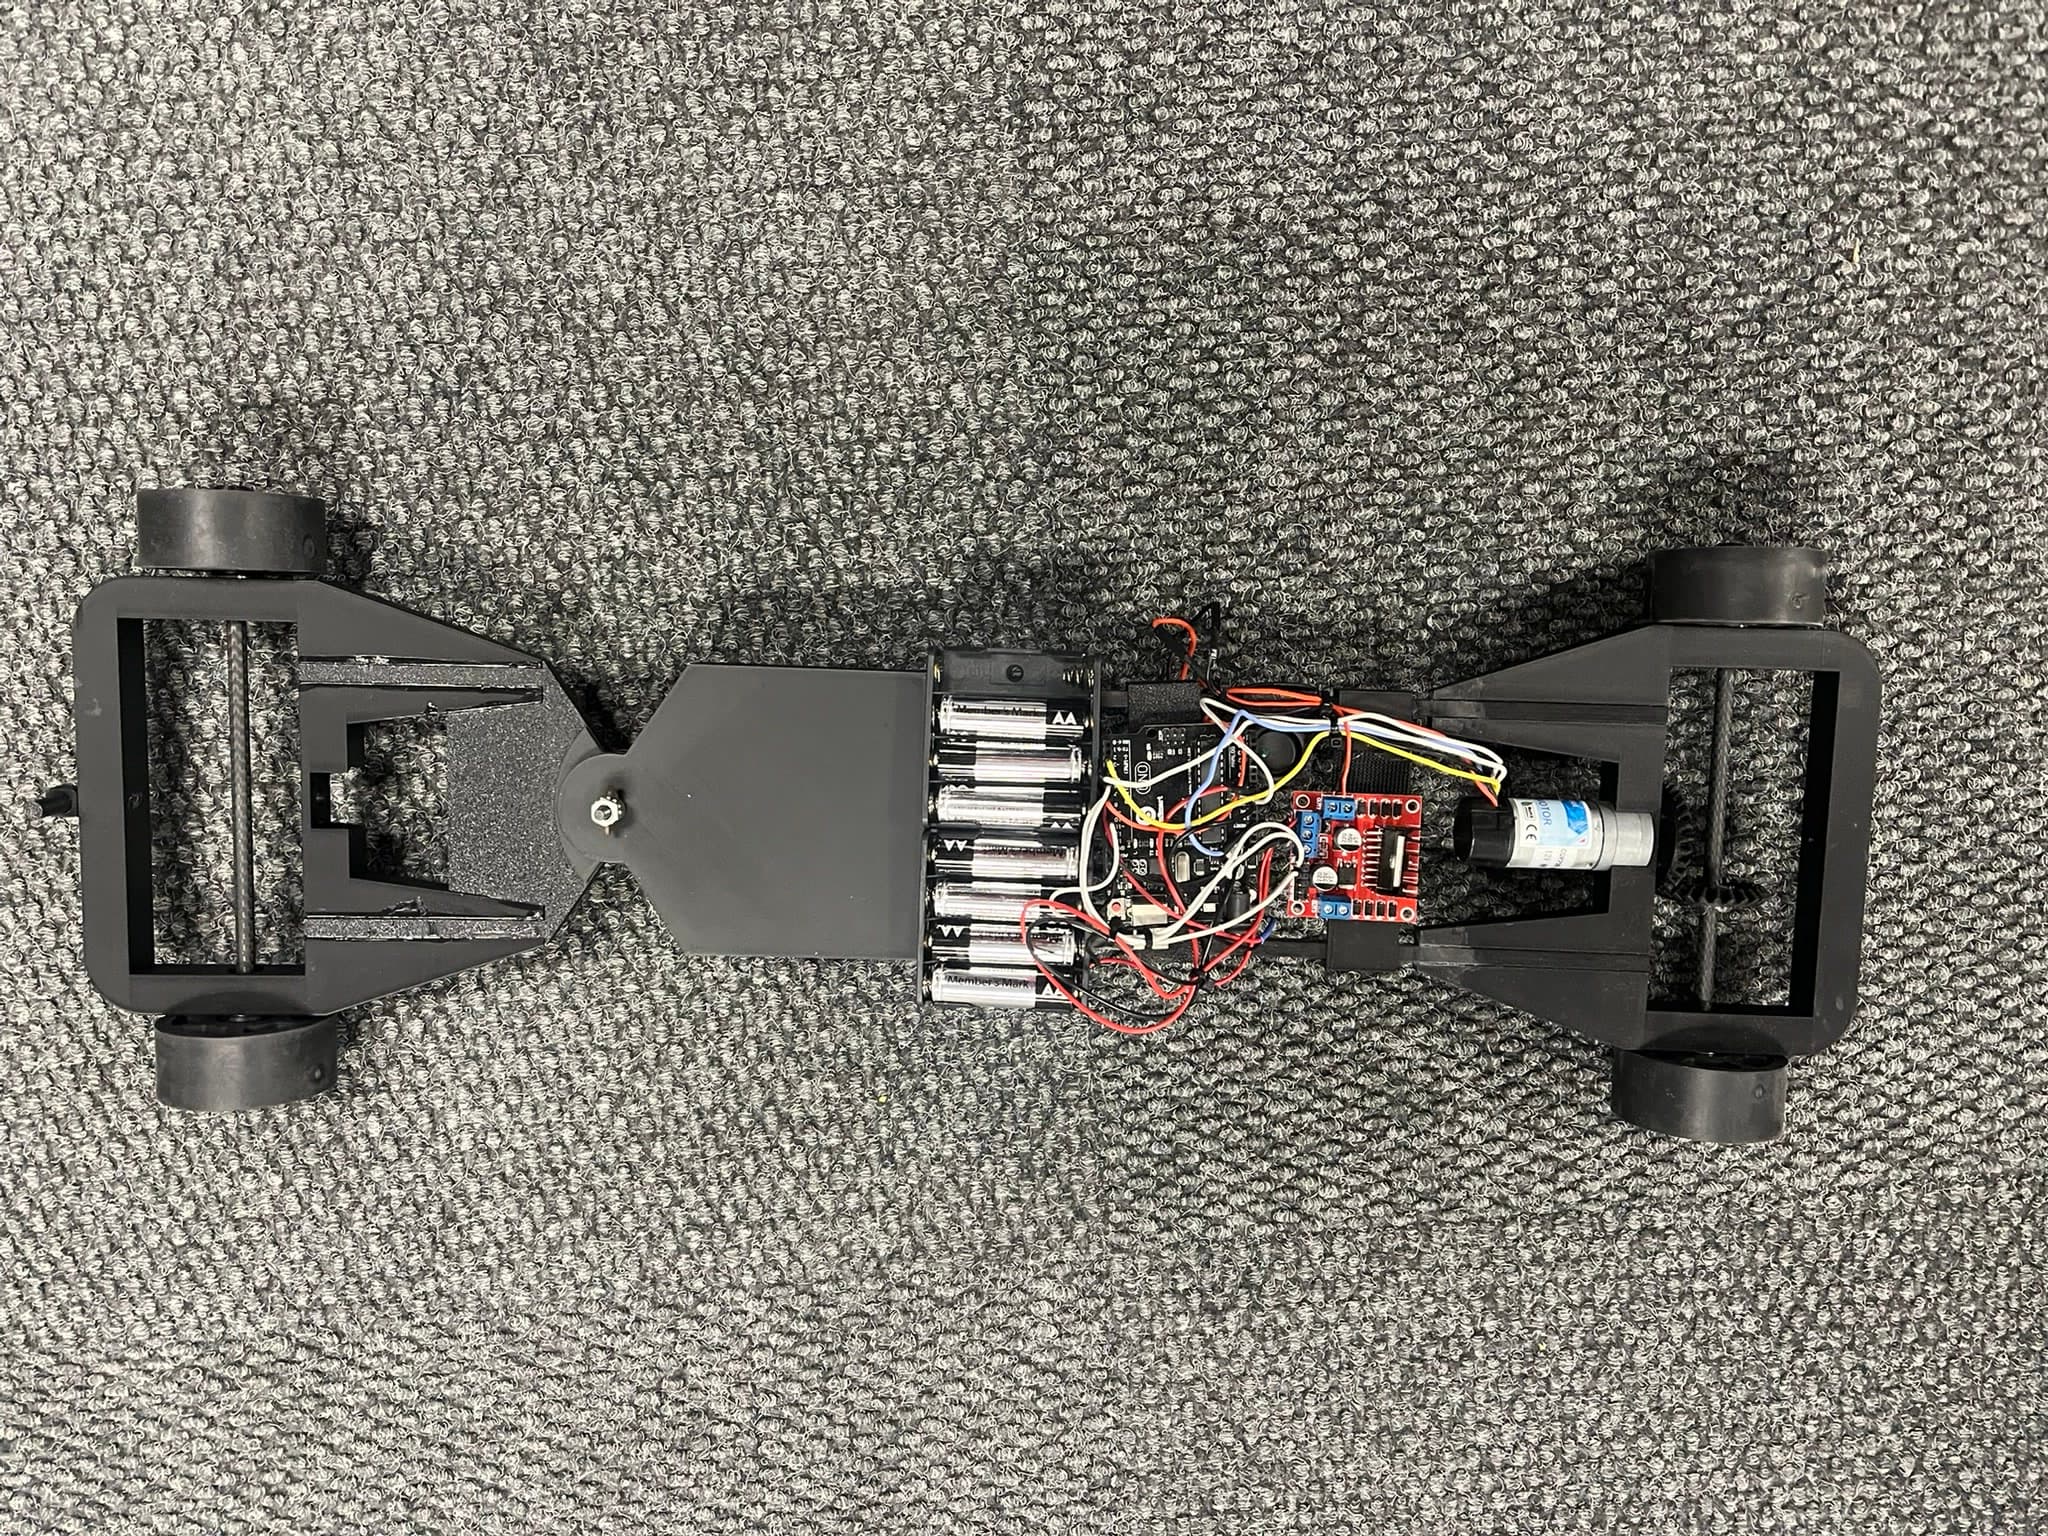
Landscape view of the final autonomous electric vehicle with its drivetrain and control electronics visible
HERO / 02Final Vehicle
01 / OVERVIEW

Encoder feedback controls target-distance stopping.

An Arduino Uno converts quadrature-encoder counts into wheel travel and commands the 12 V drivetrain through an L298N motor driver.
02 / VEHICLE + DRIVETRAIN
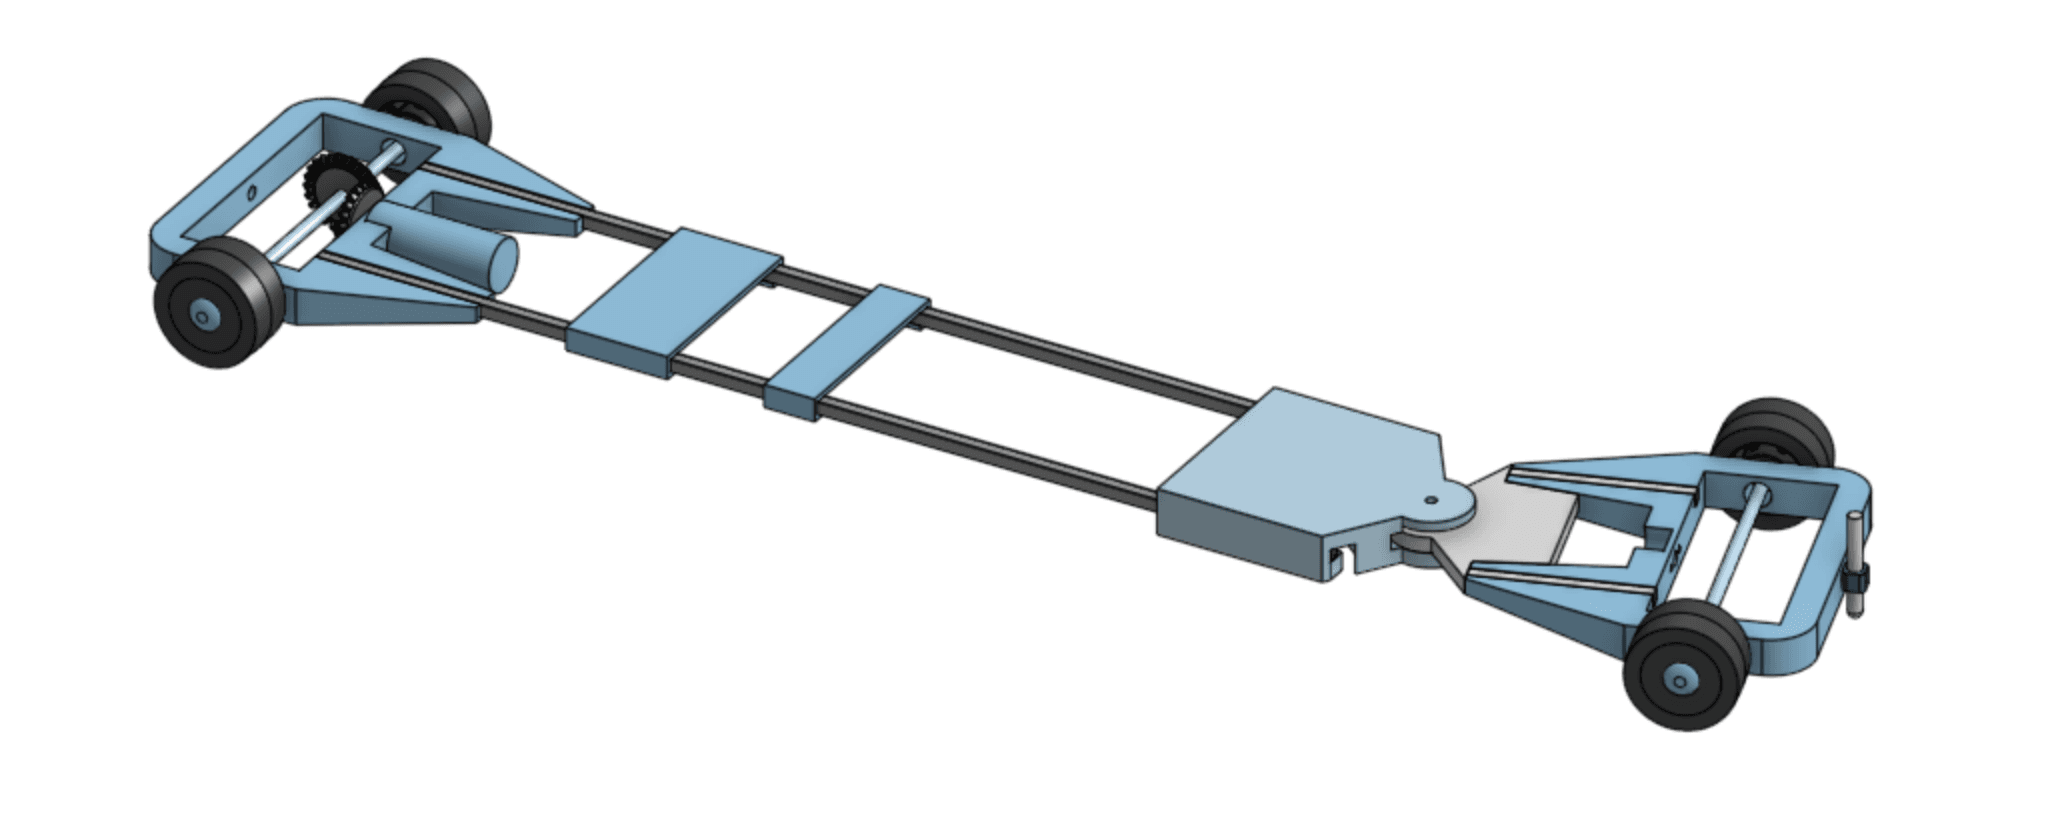
CAD model of the autonomous electric vehicle chassis and drivetrain
02 / 01Vehicle CAD
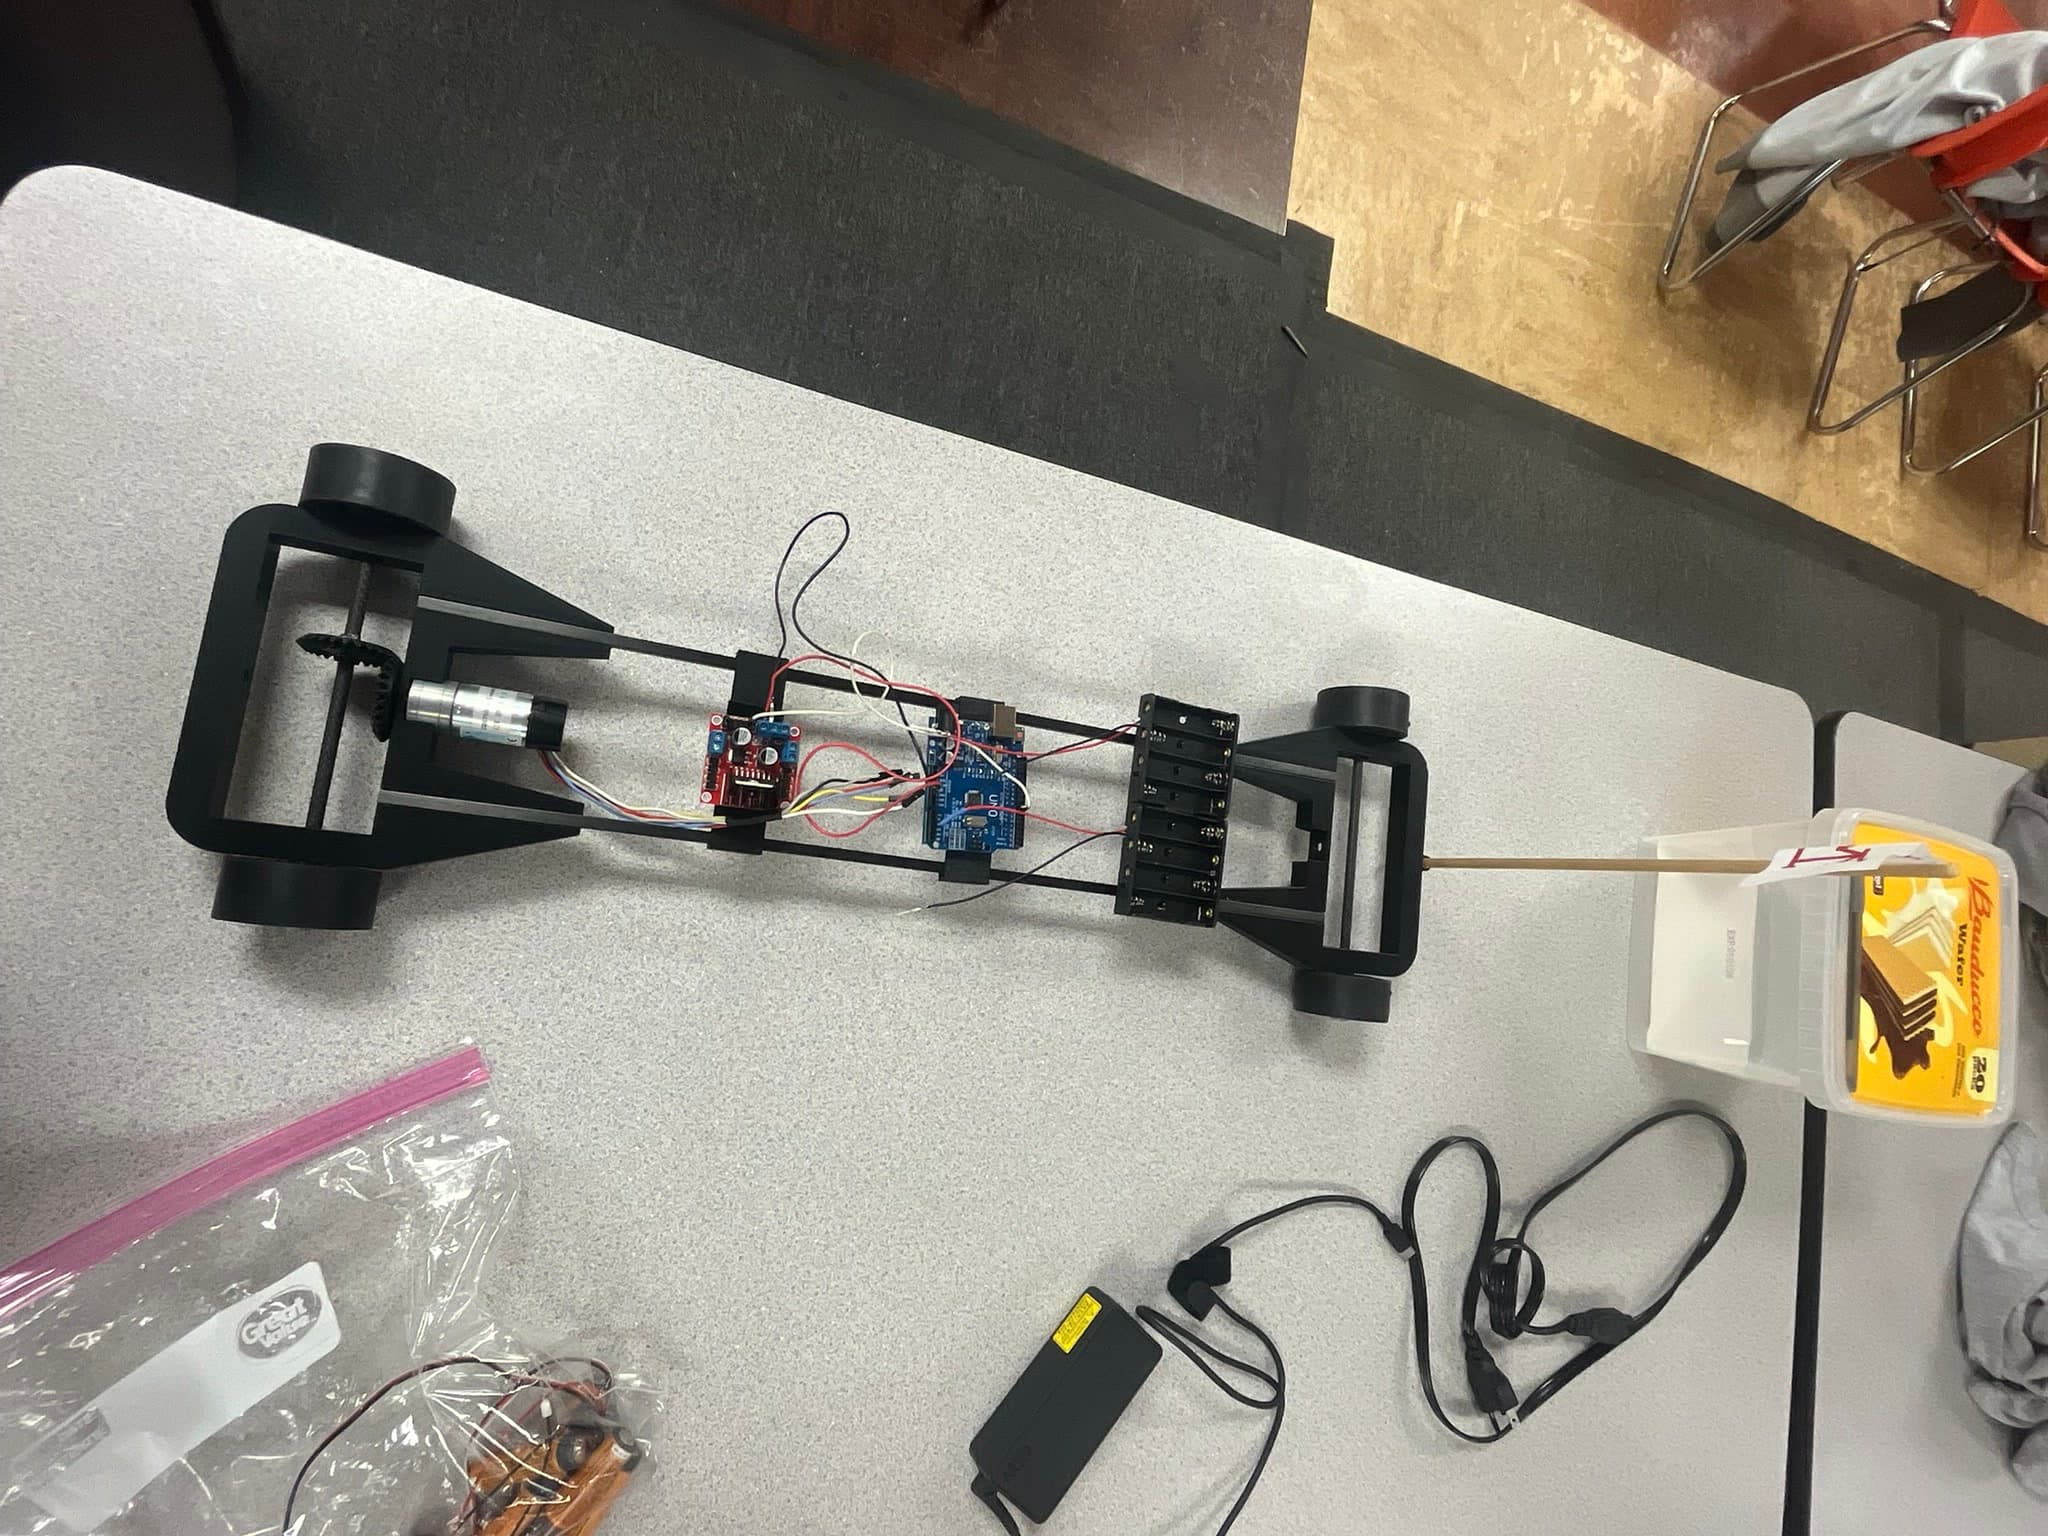
Landscape view of the assembled autonomous electric vehicle prepared for testing
02 / 02Assembled Vehicle

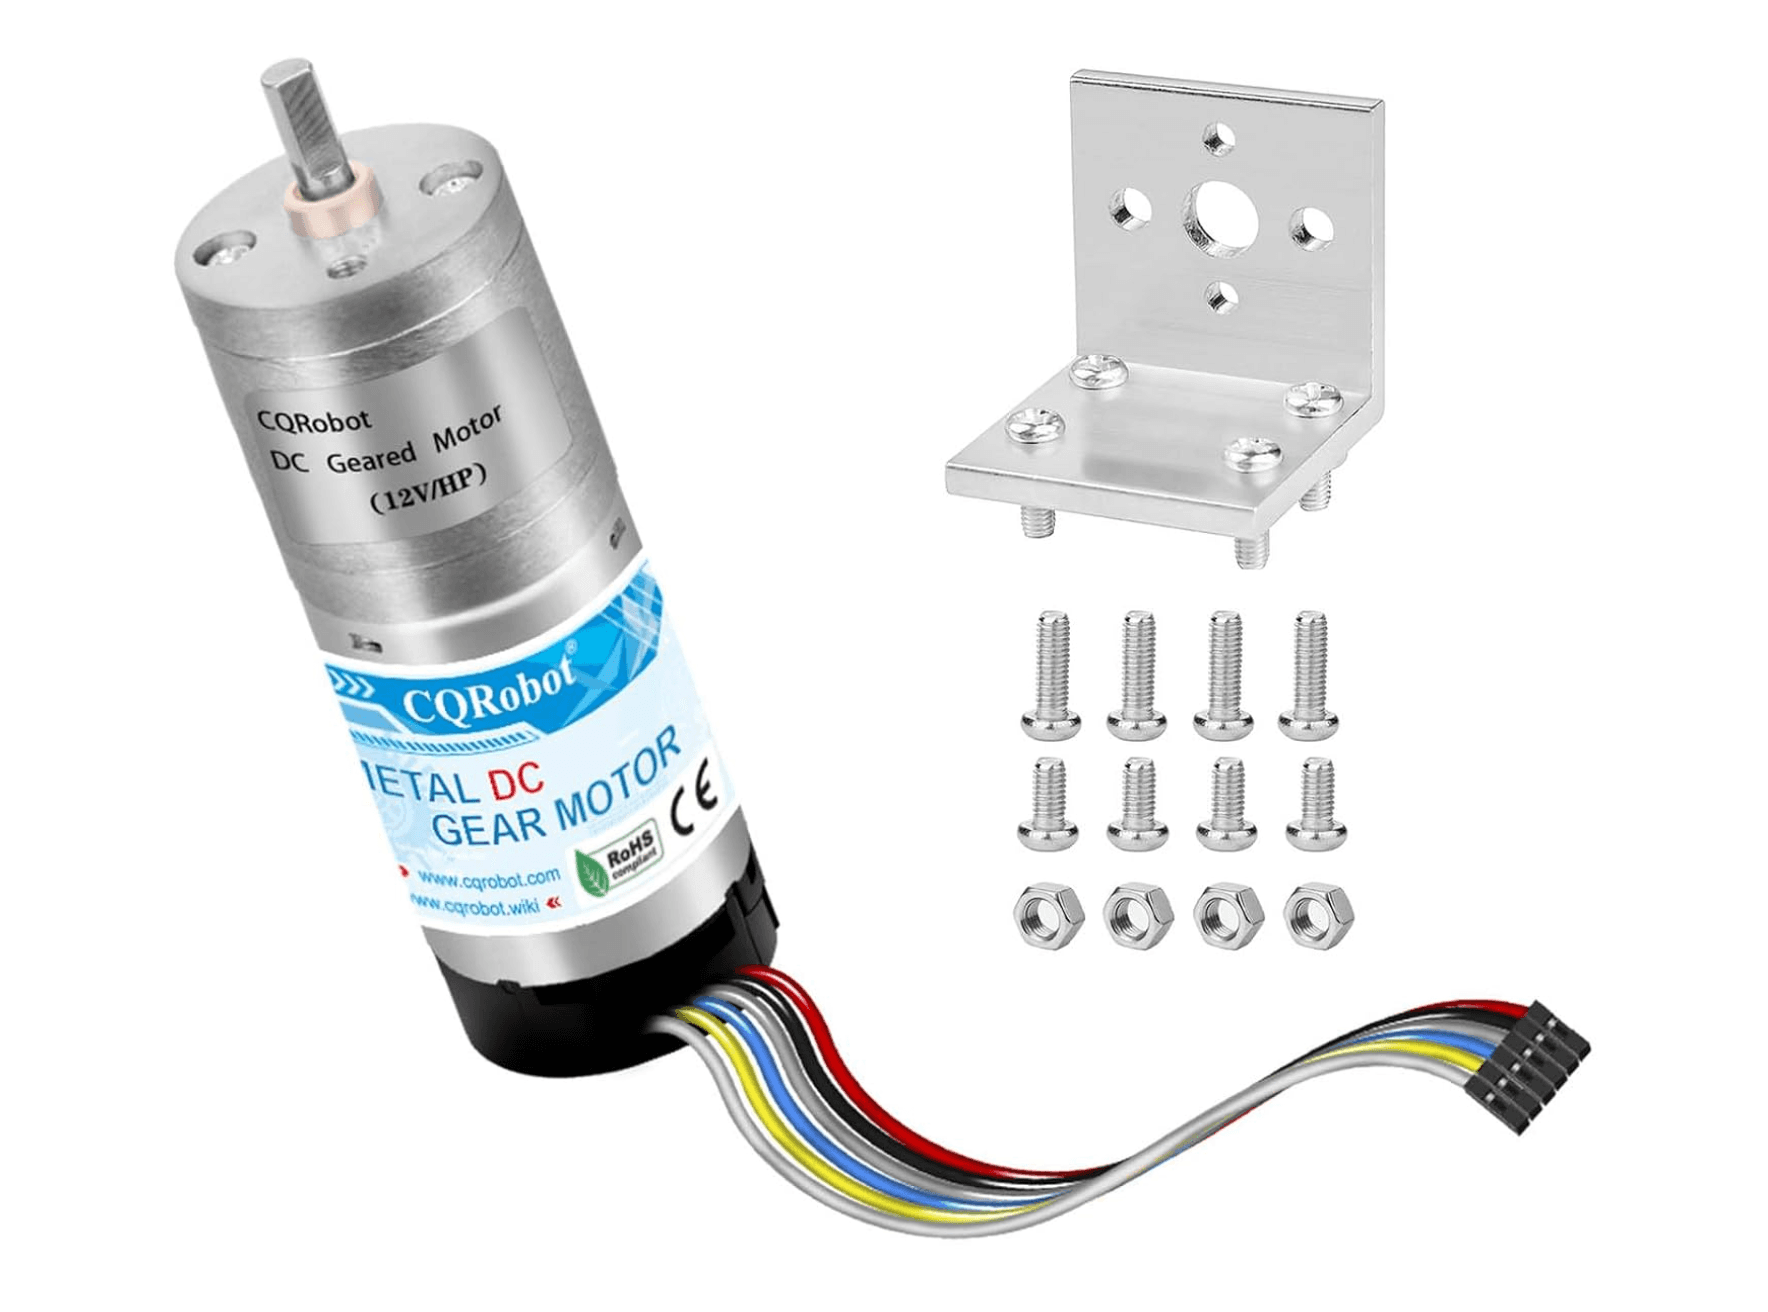
Built the mechanical chassis and drivetrain around a 12 V 4.4:1 25D metal DC gearmotor. The two vehicle configurations reflect different season requirements: the first season used a straight-line course, while the second used a curved track.
03 / CONTROL + ELECTRONICS
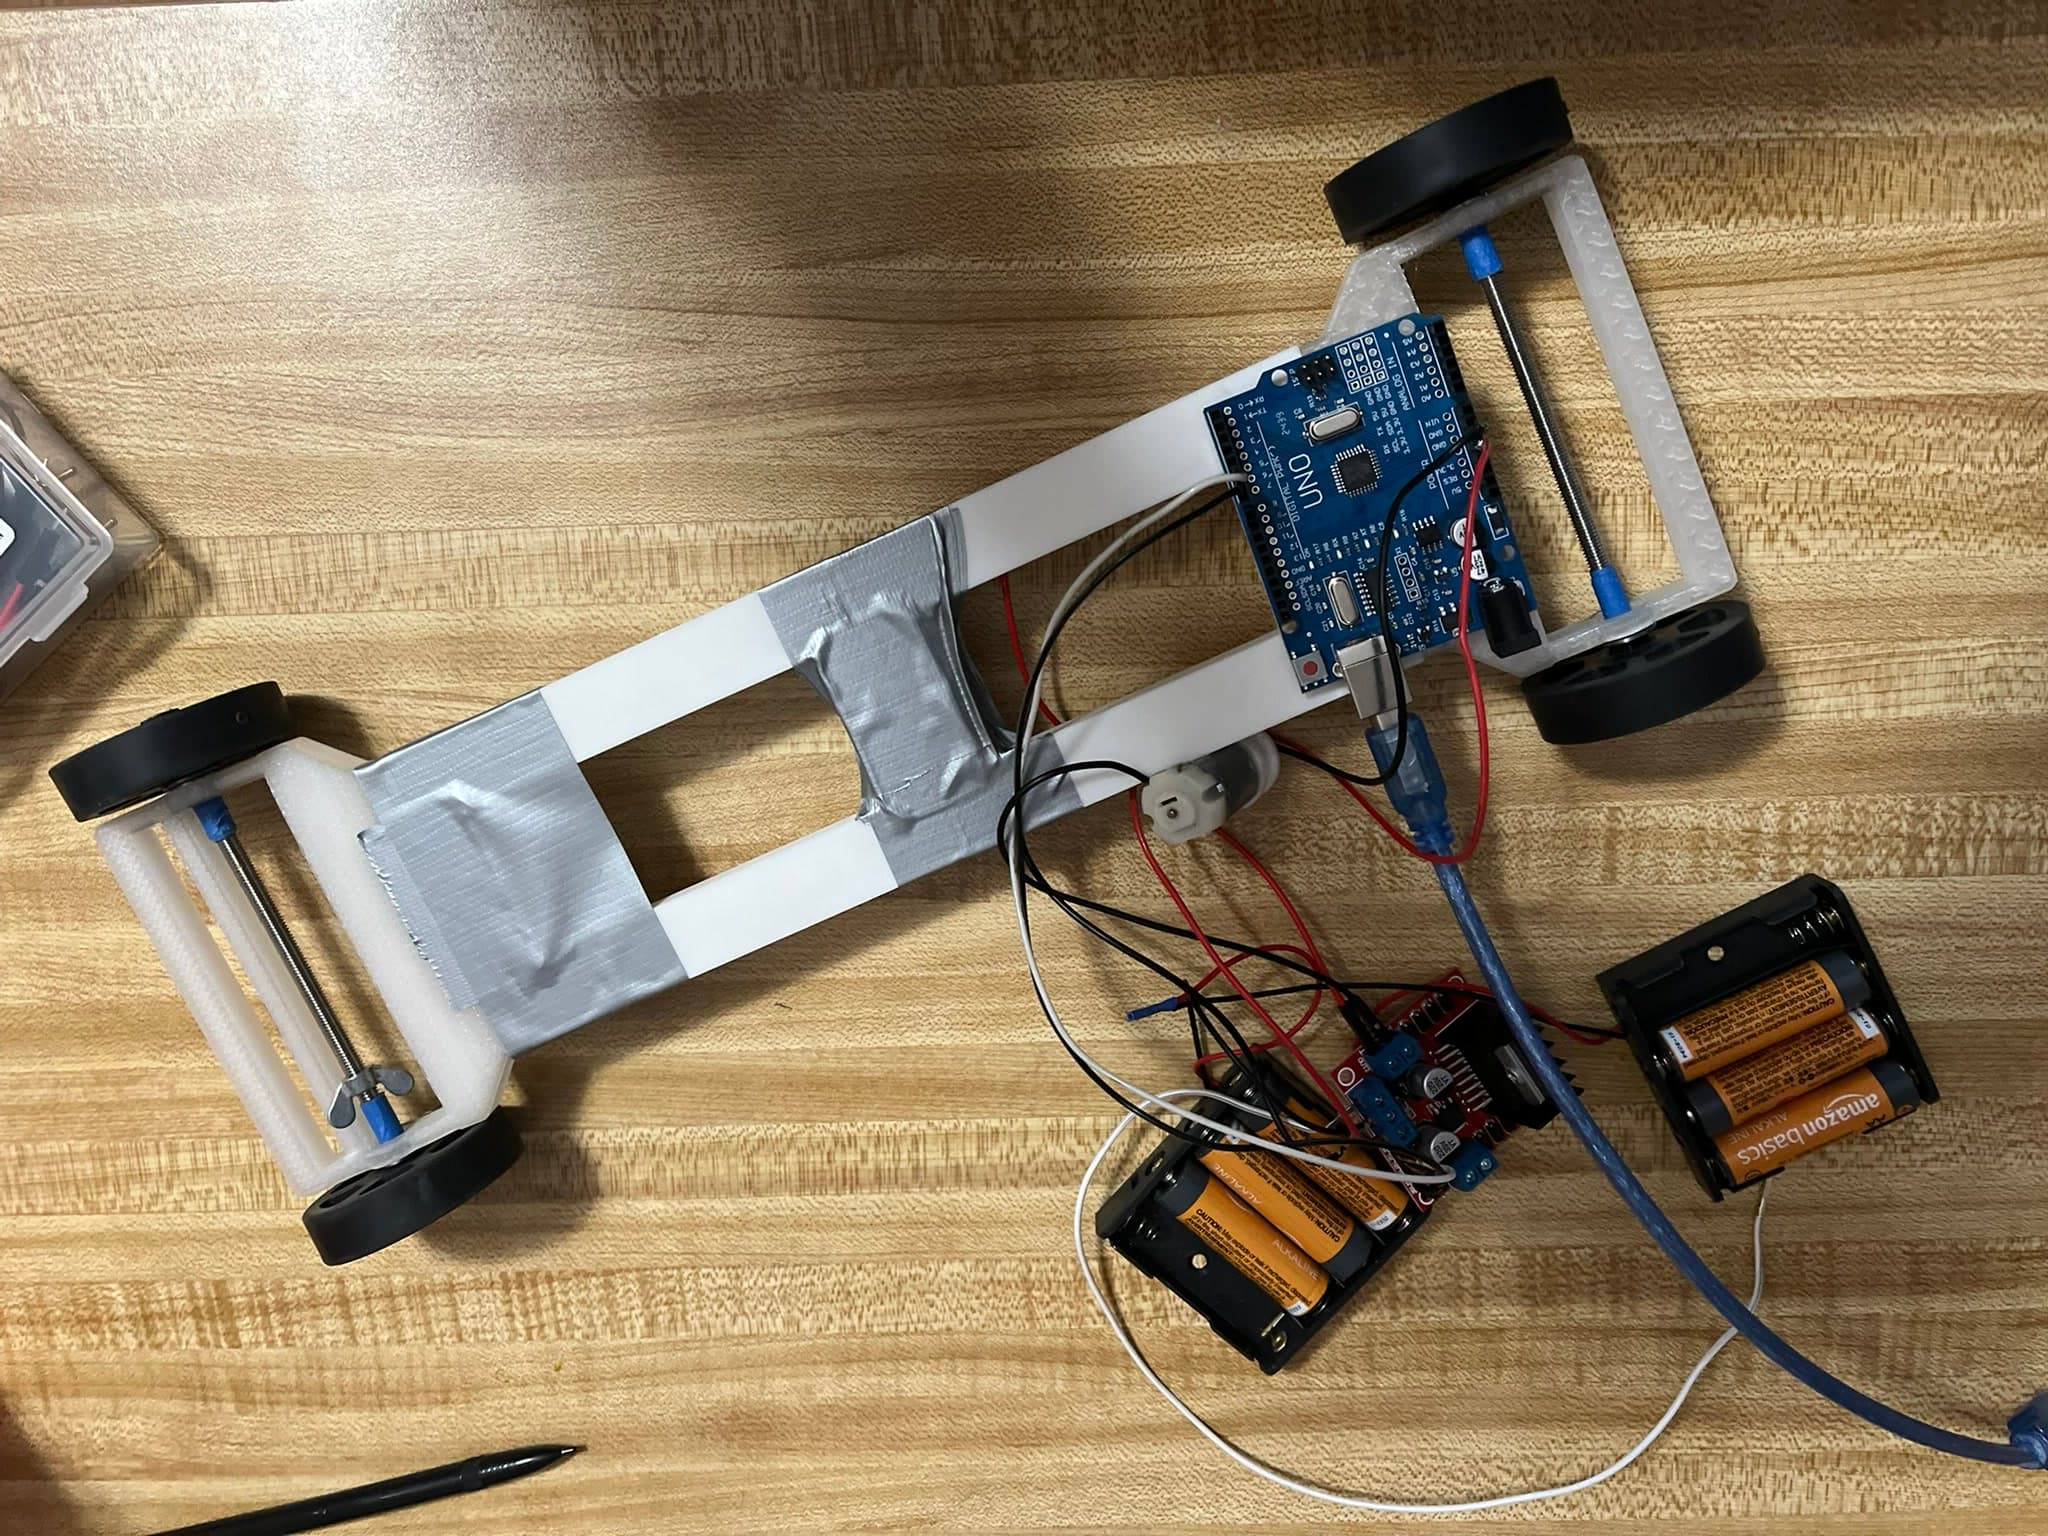
Landscape view of the early electric vehicle prototype with Arduino Uno, motor driver, and wiring
03 / 01Prototype Electronics
25D metal DC gearmotor with quadrature encoder
03 / 02Motor + Encoder

An Arduino Uno commands the motor through an L298N motor driver while a 48 CPR quadrature encoder provides motion feedback, within the event's eight-AA-battery limit.

04 / ENCODER FEEDBACK
Landscape view of the final vehicle showing the integrated motor, driver, Arduino, wiring, and chassis
04 / 01Integrated Vehicle Electronics
04 / 02Build + Testing Timelapse

Wheel-distance calibration converts encoder counts into vehicle position during each run.