PROJECT / 02FLIGHT SYSTEMS / CONTROLS / VISION
3D-Printed Quadcopter Drone
Designed a Nylon-CF quadcopter frame with TPU soft grippers, asymmetric-payload stabilization, PID control, and onboard object detection.
Mechanical DesignNylon-CFAdditive ManufacturingPID ControlComputer VisionPrototyping
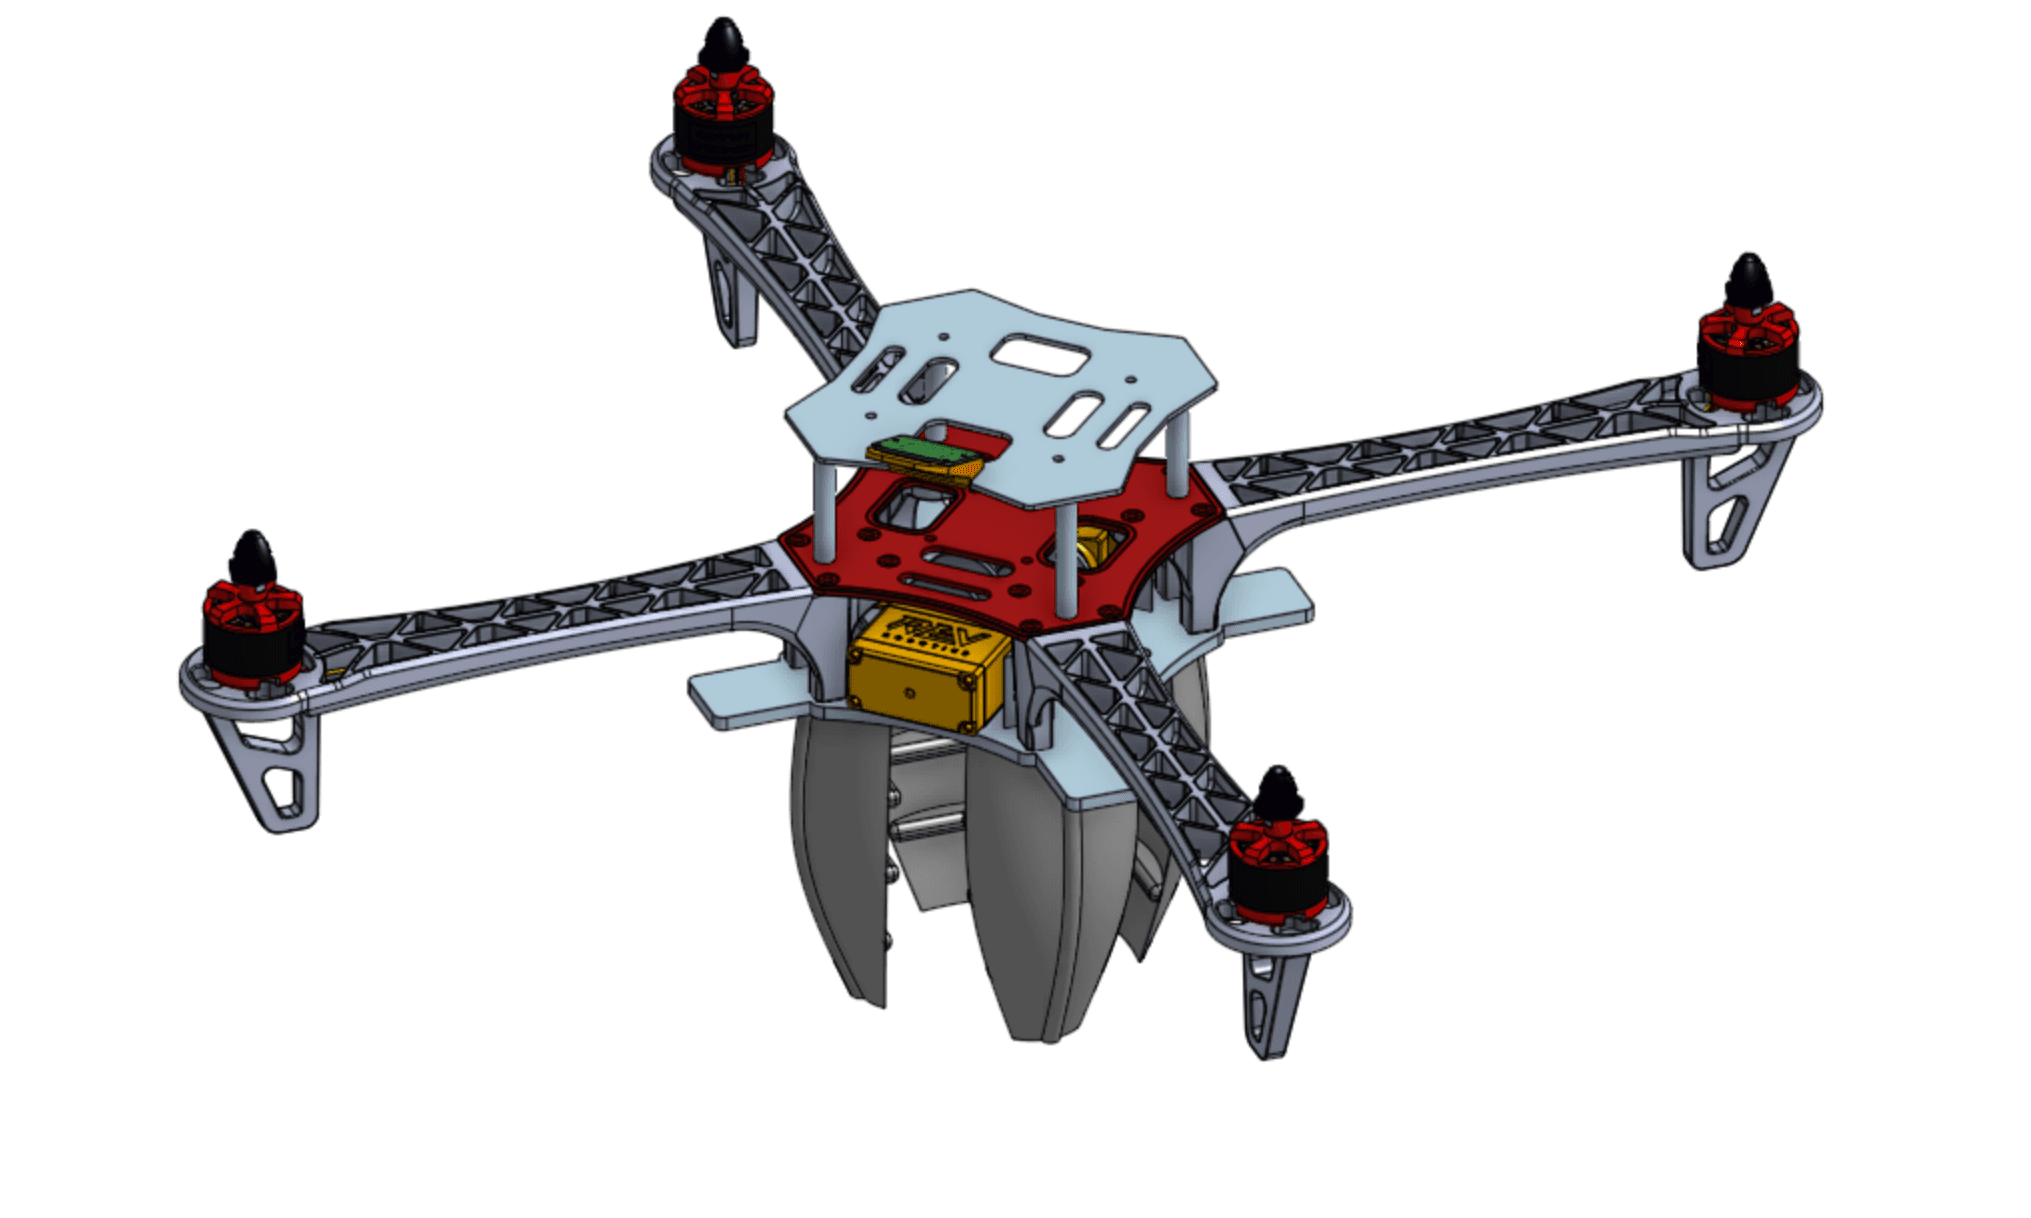
A printed airframe integrating flight control and manipulation.
The Nylon-CF frame carries stacked flight electronics, PID stabilization for asymmetric payloads, onboard object detection, and a central TPU soft gripper.
Rigid and compliant grippers explored two approaches to aerial manipulation.
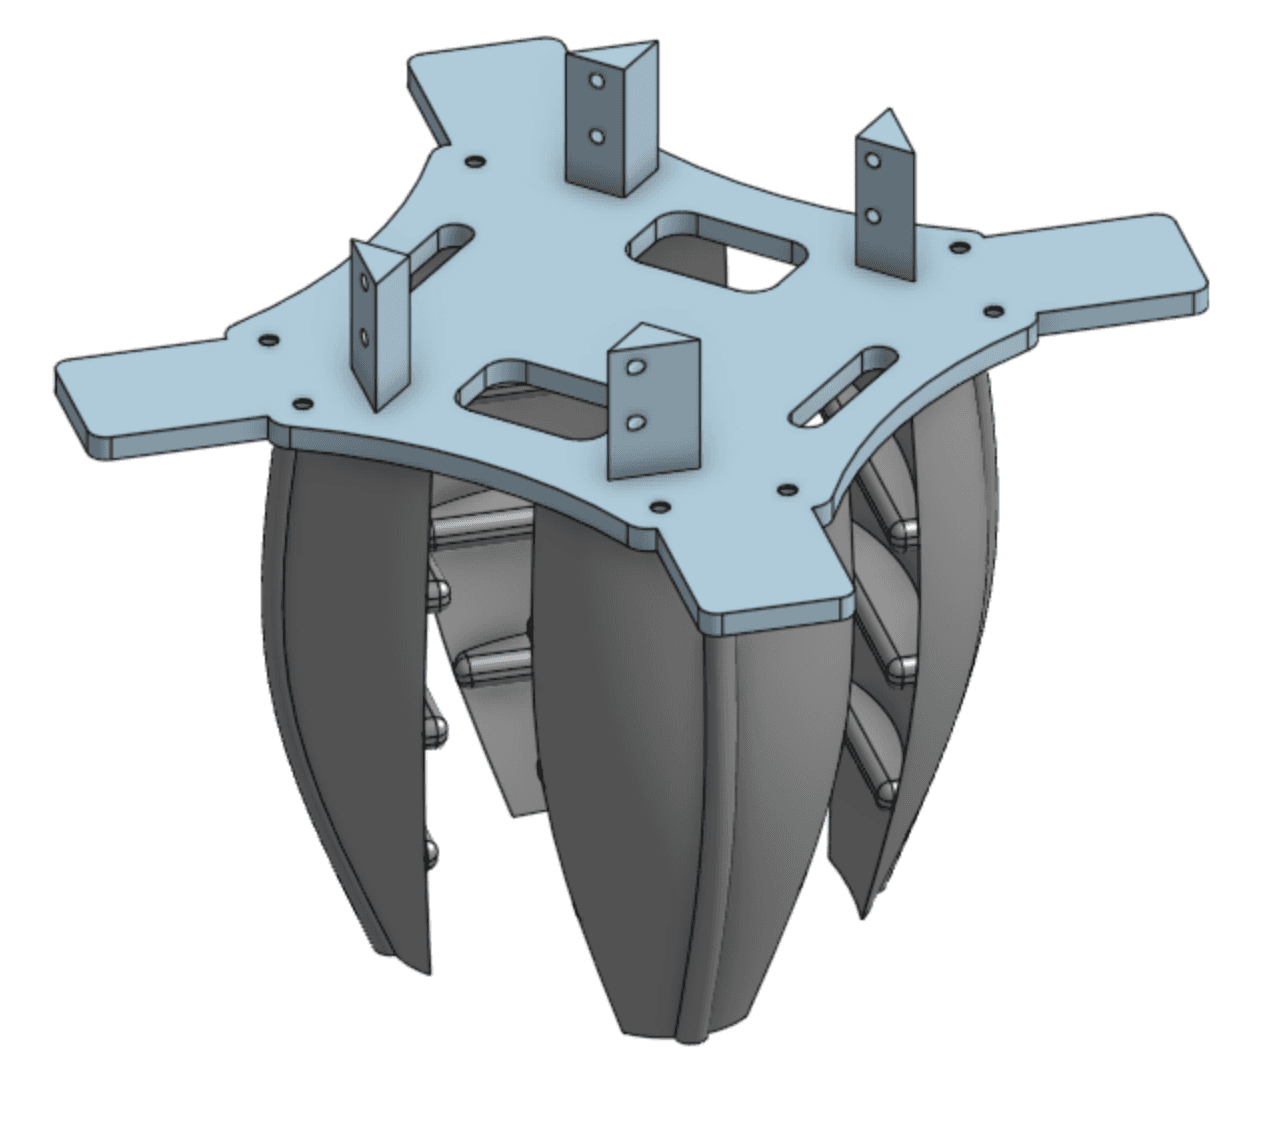
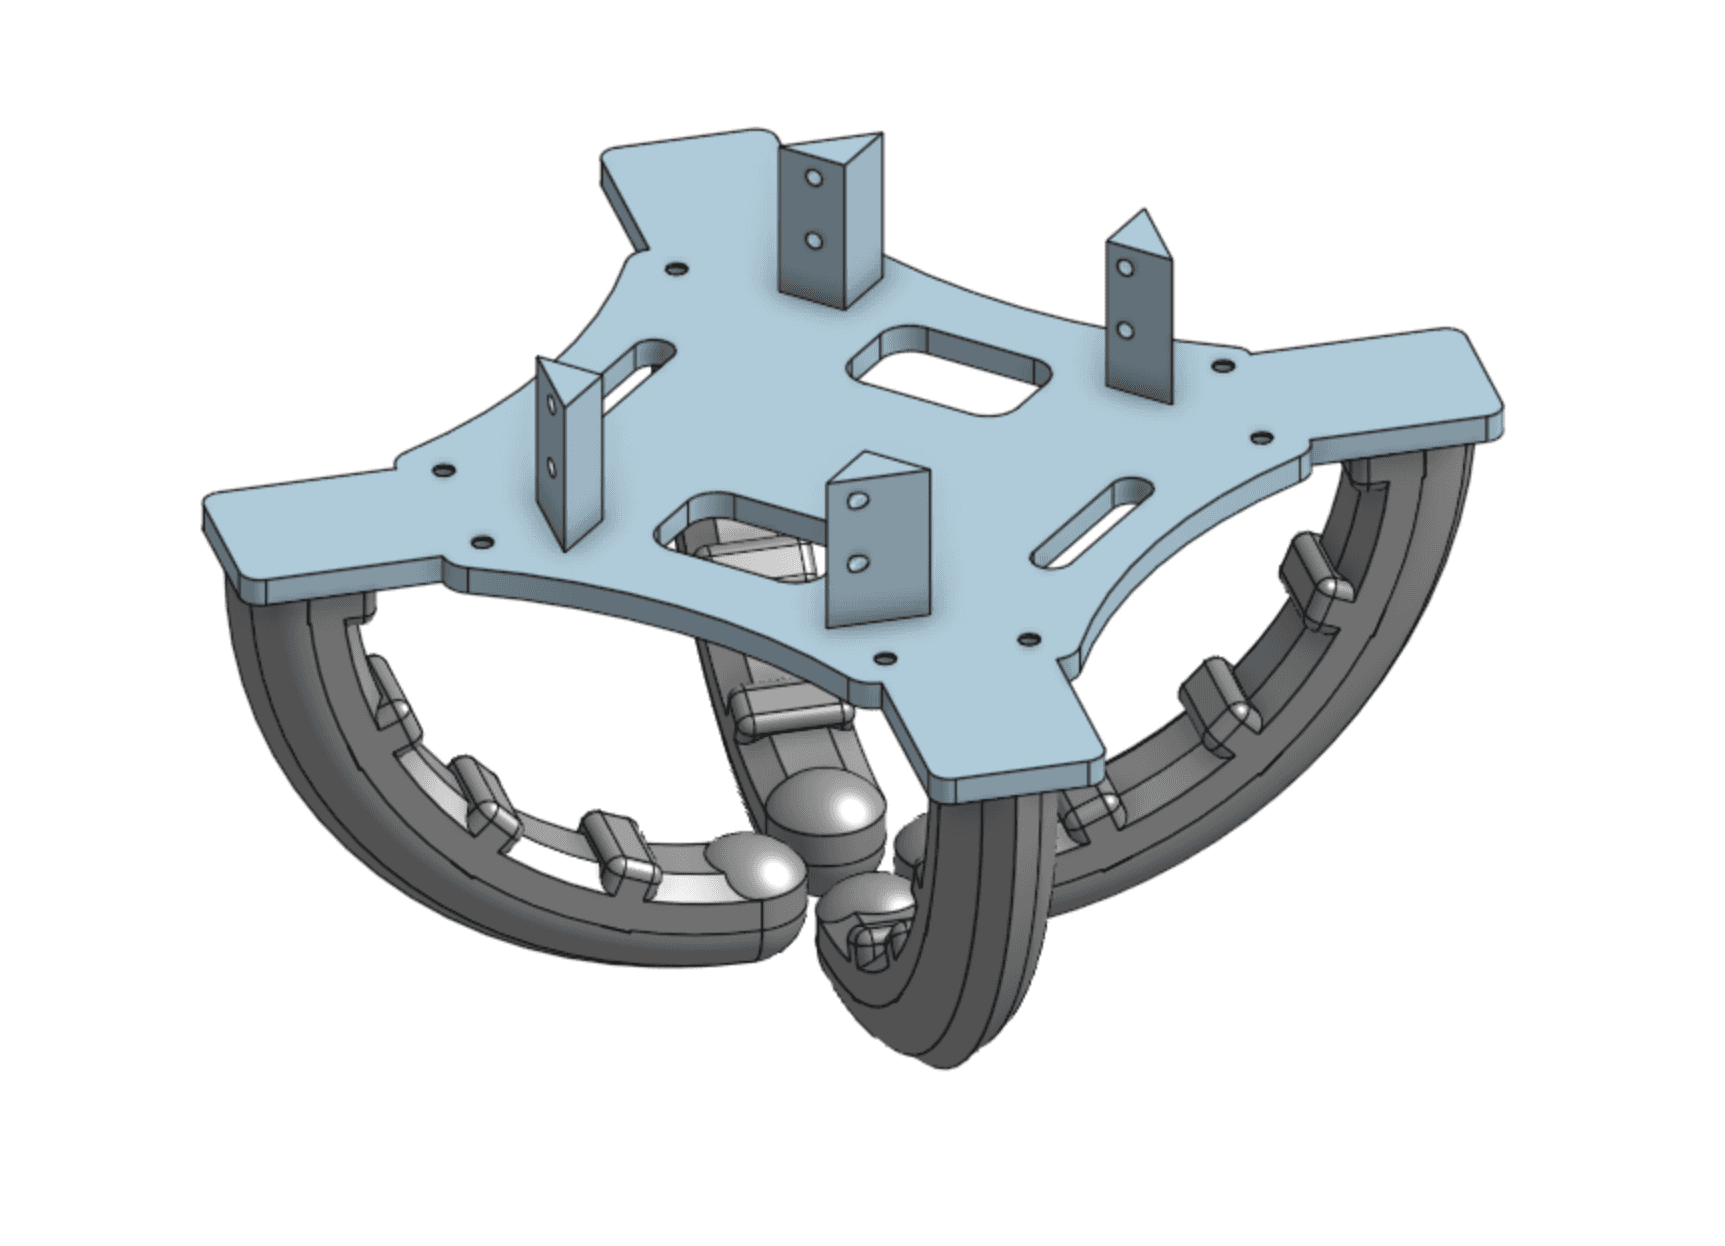
A rigid claw established the mounting geometry, while the soft gripper introduced compliant contact for more adaptable object handling.
Printing and airframe integration.
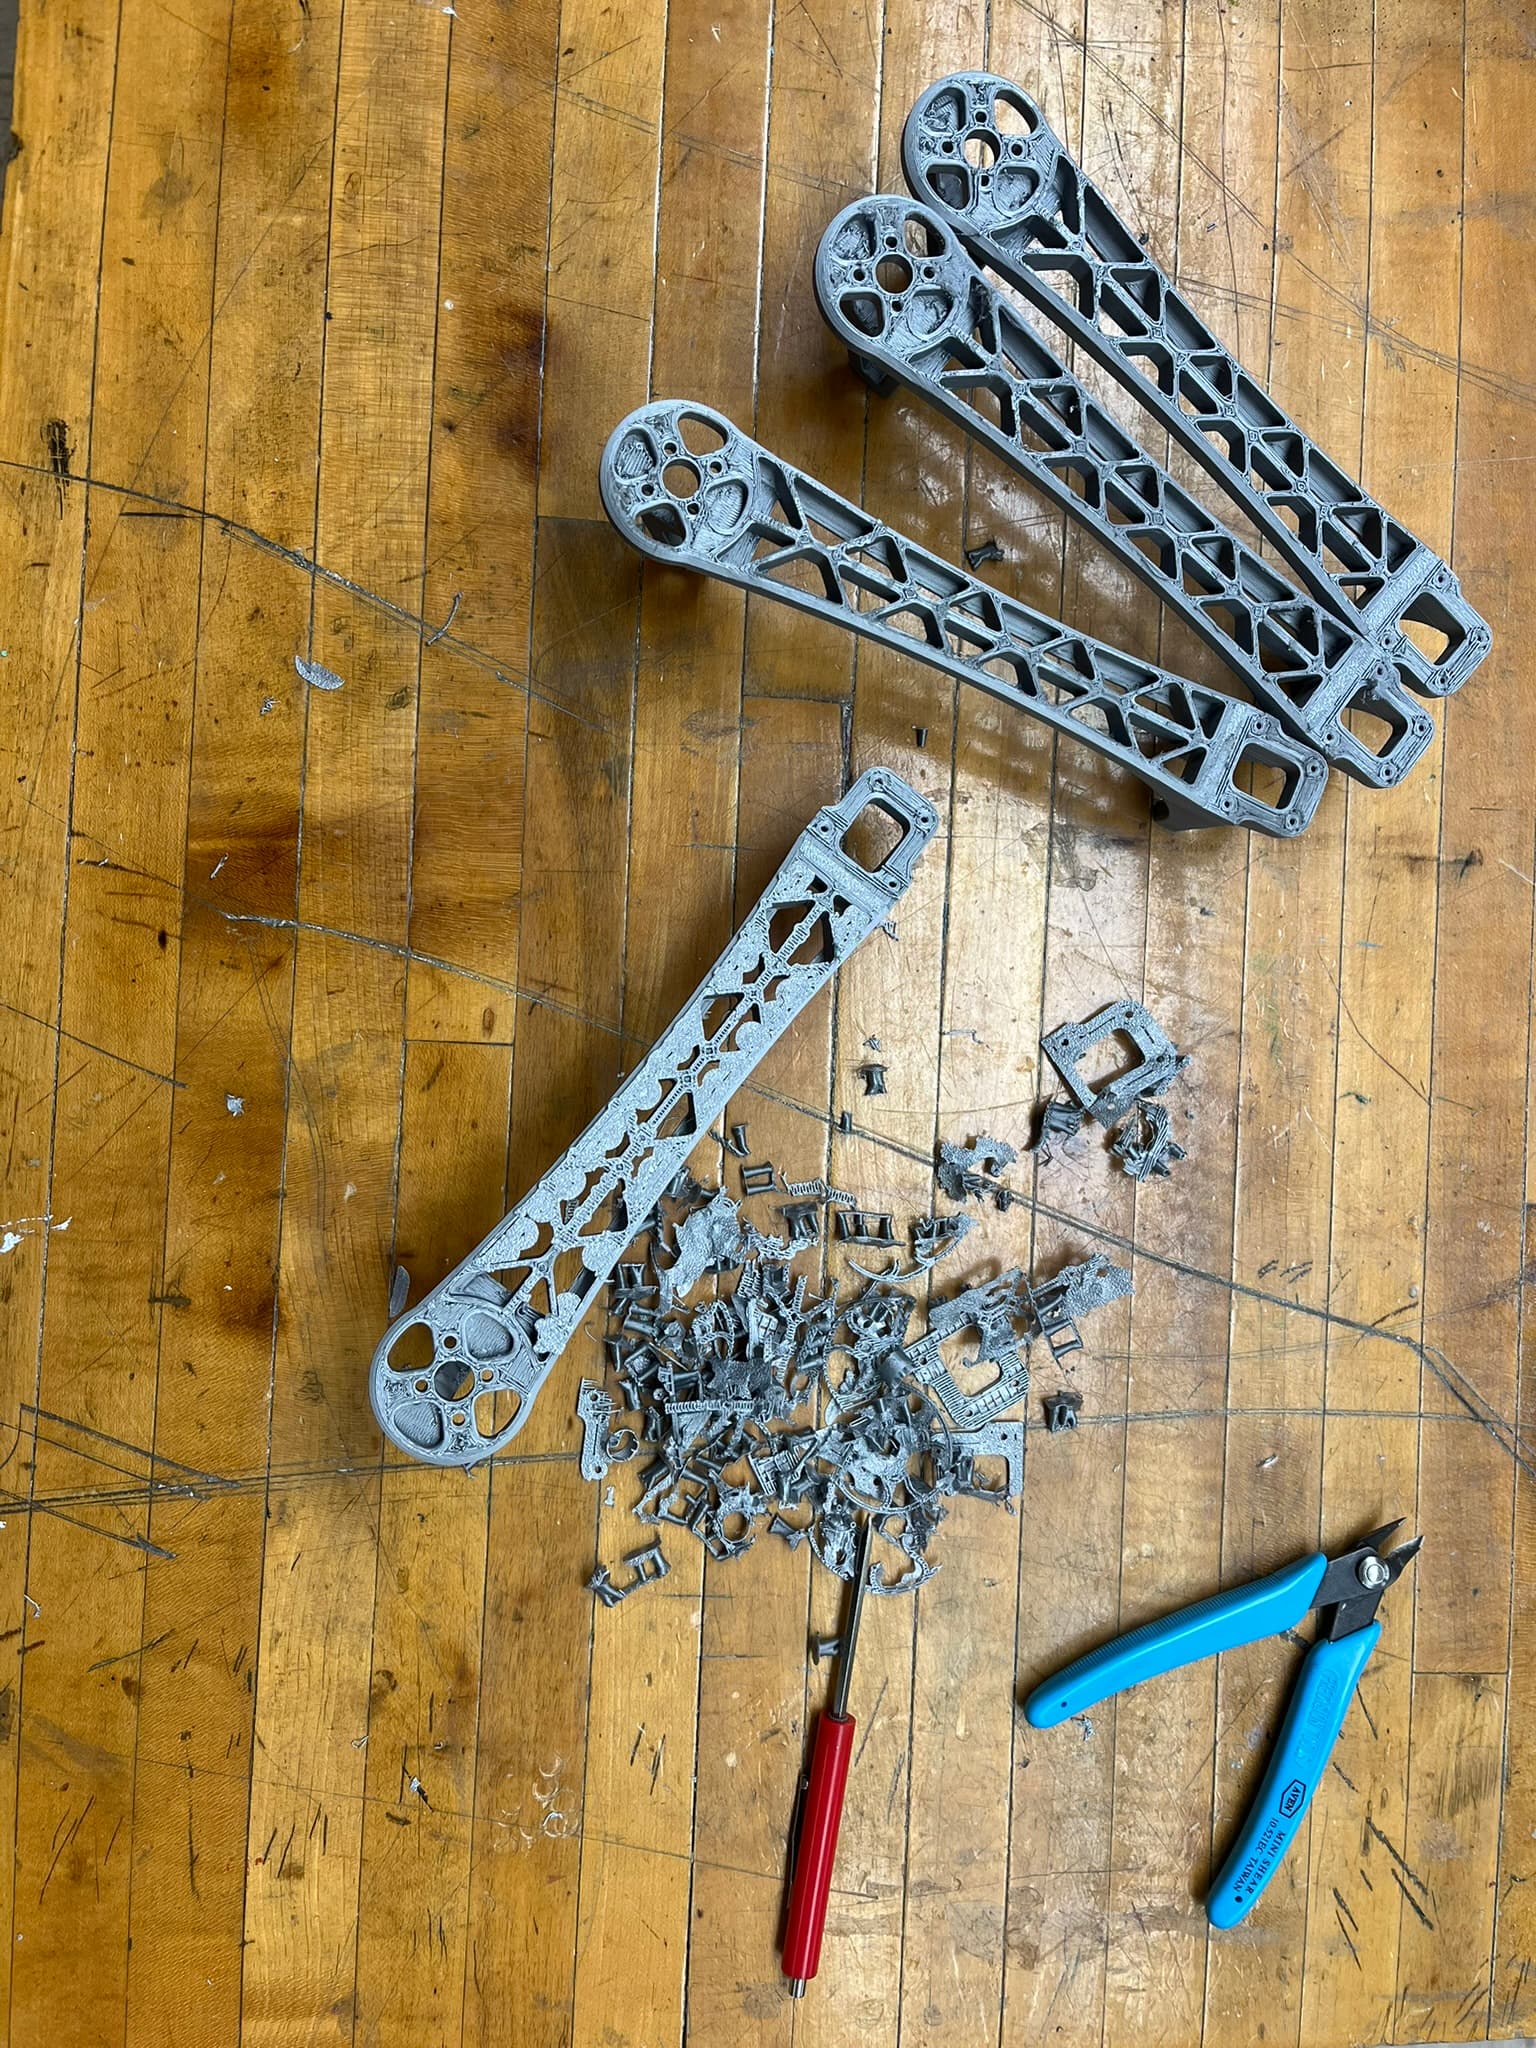
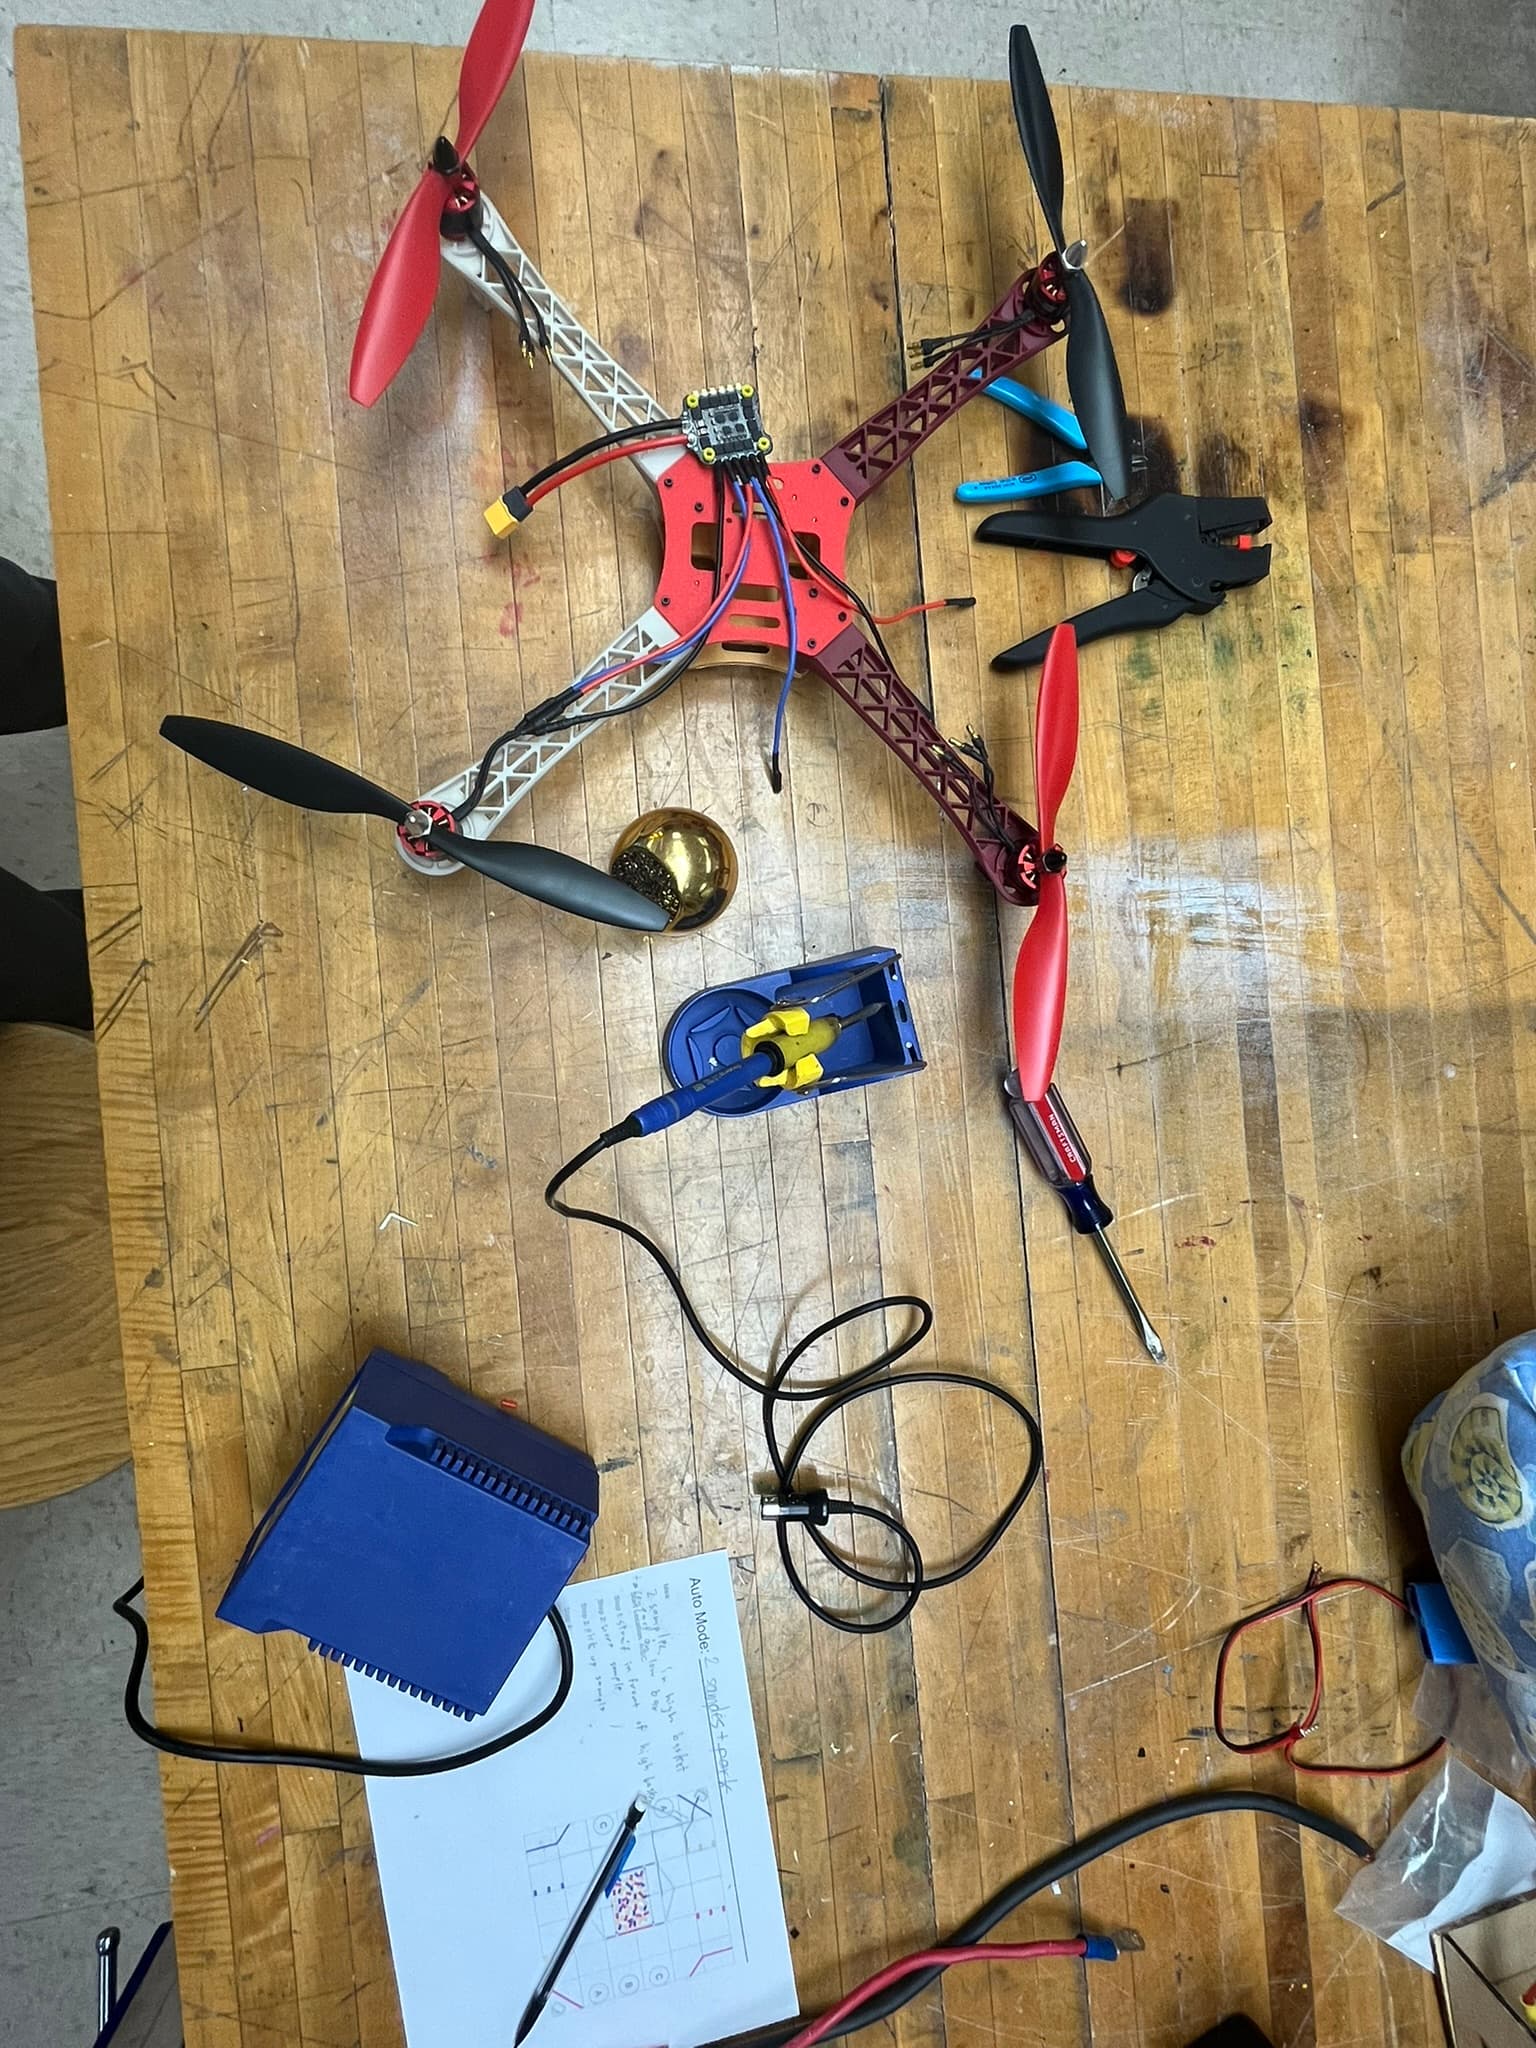
The Nylon-CF arms were printed, cleaned, assembled, and wired before integration with the electronics and propulsion system.
A printed quadcopter structured around flight and manipulation.
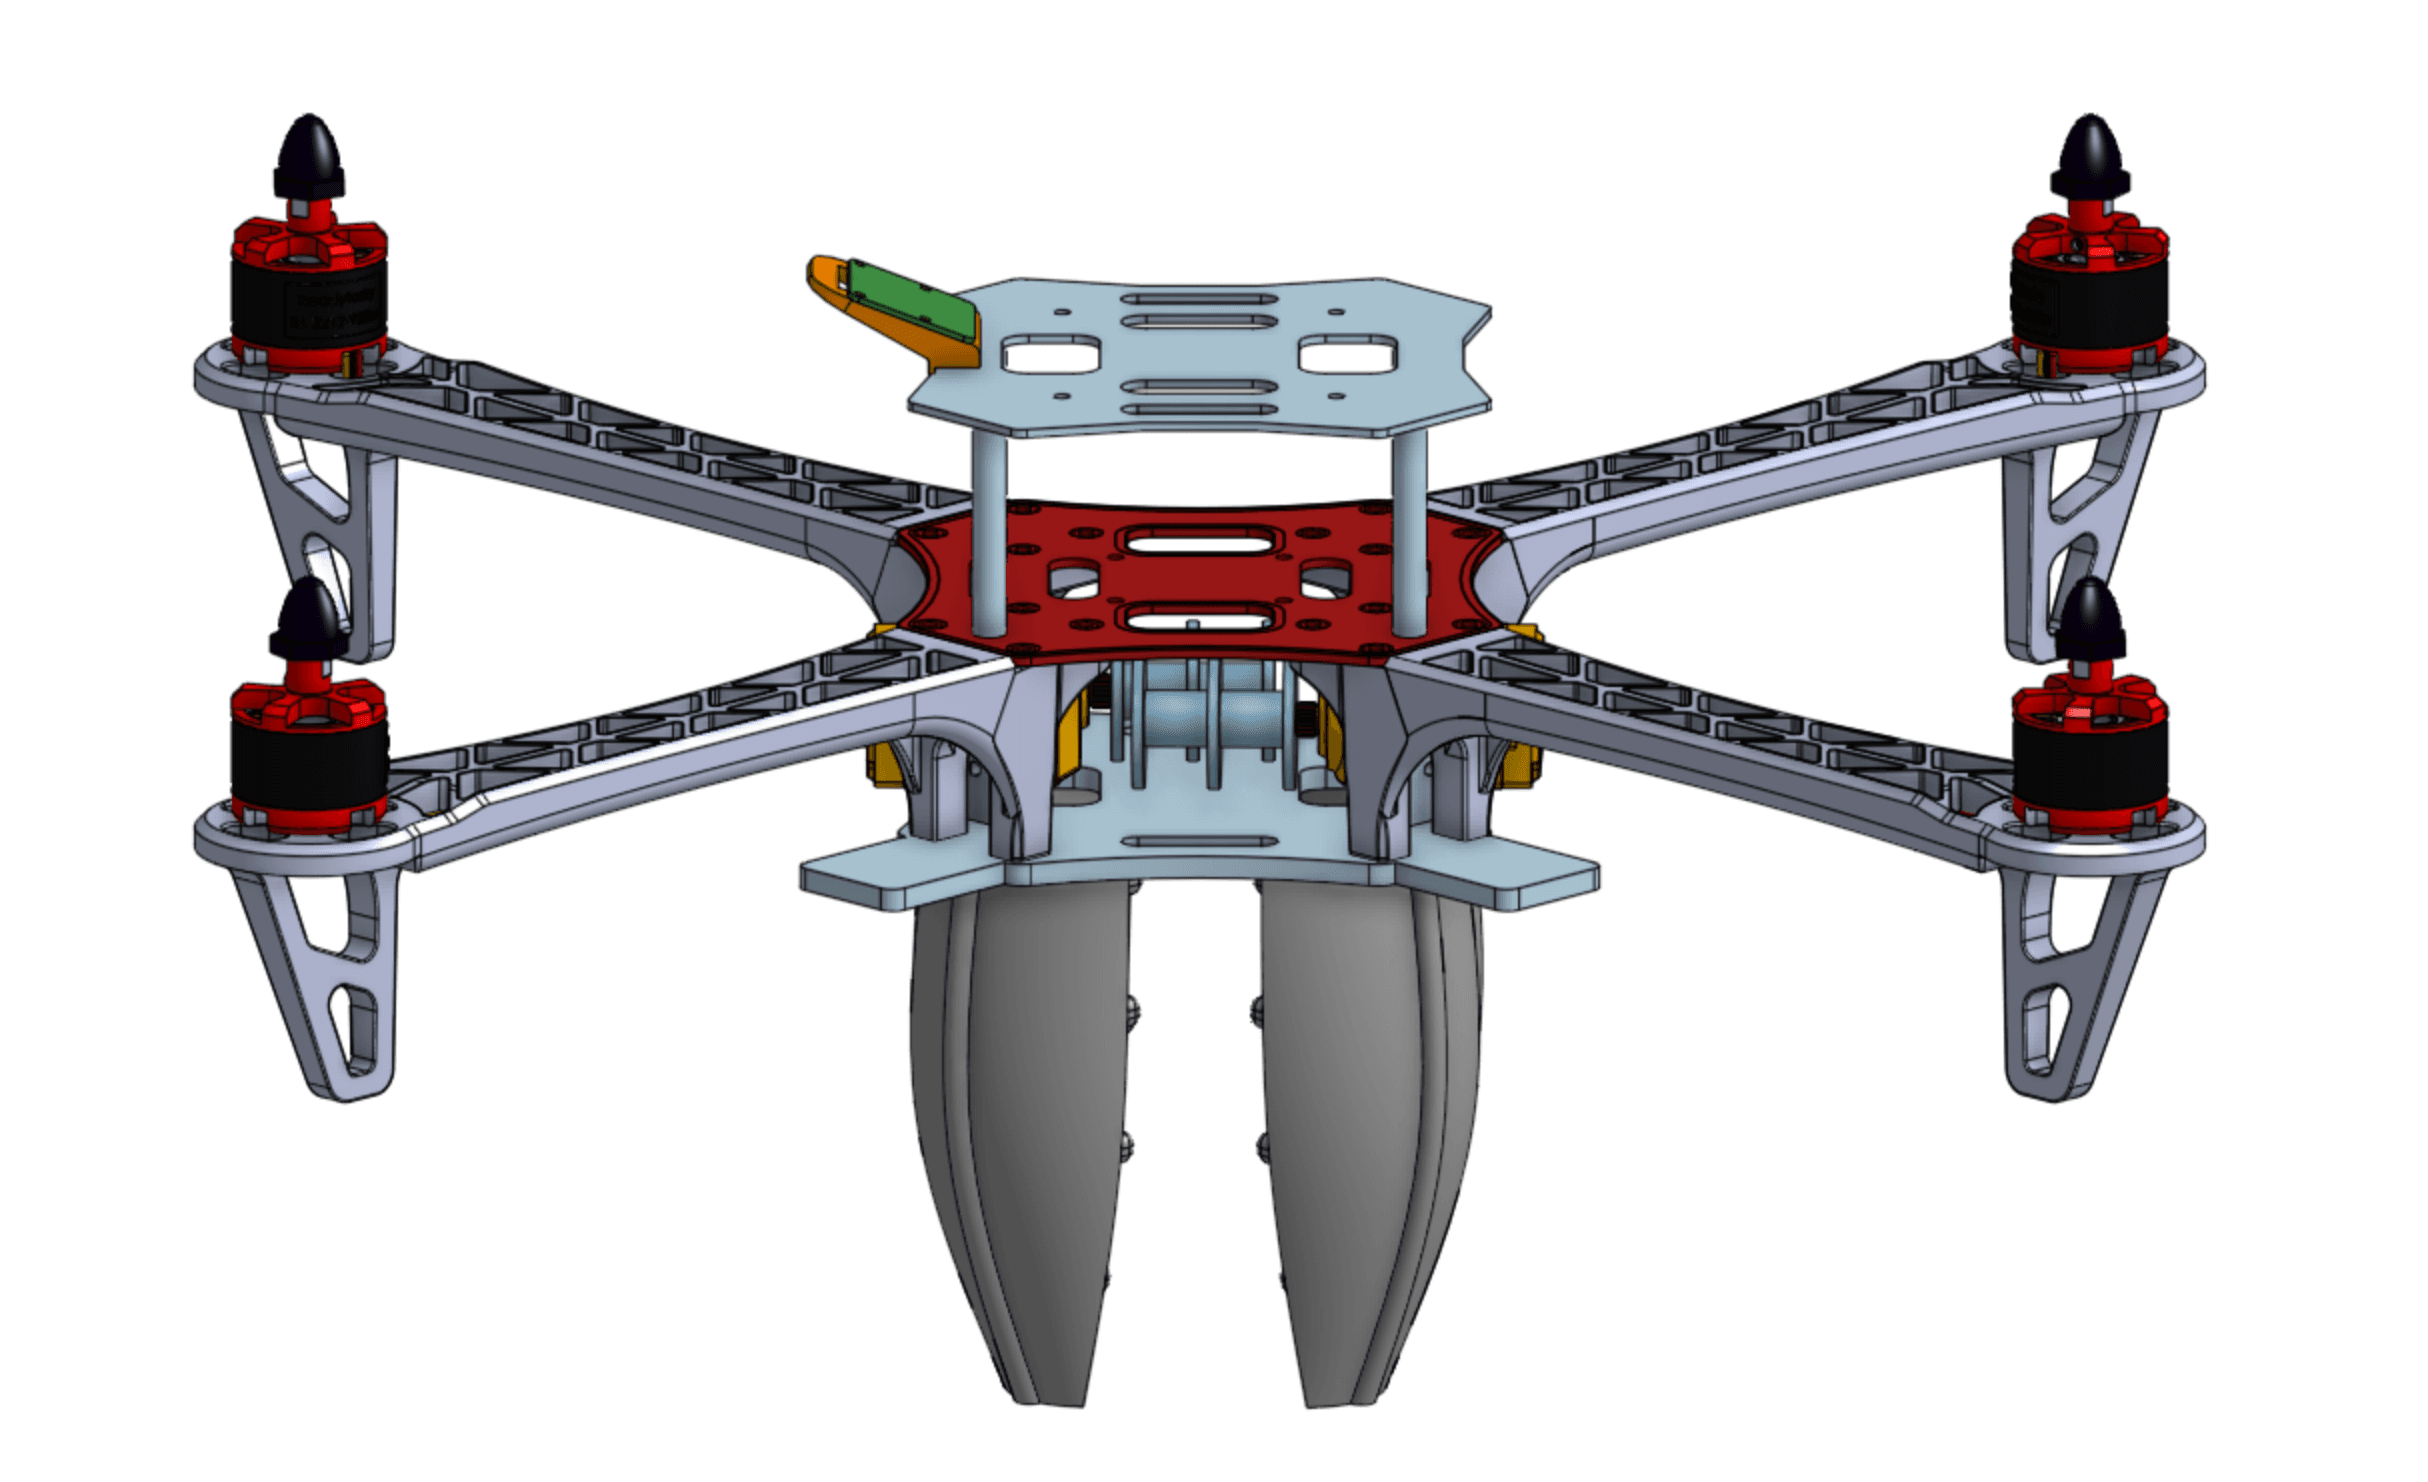
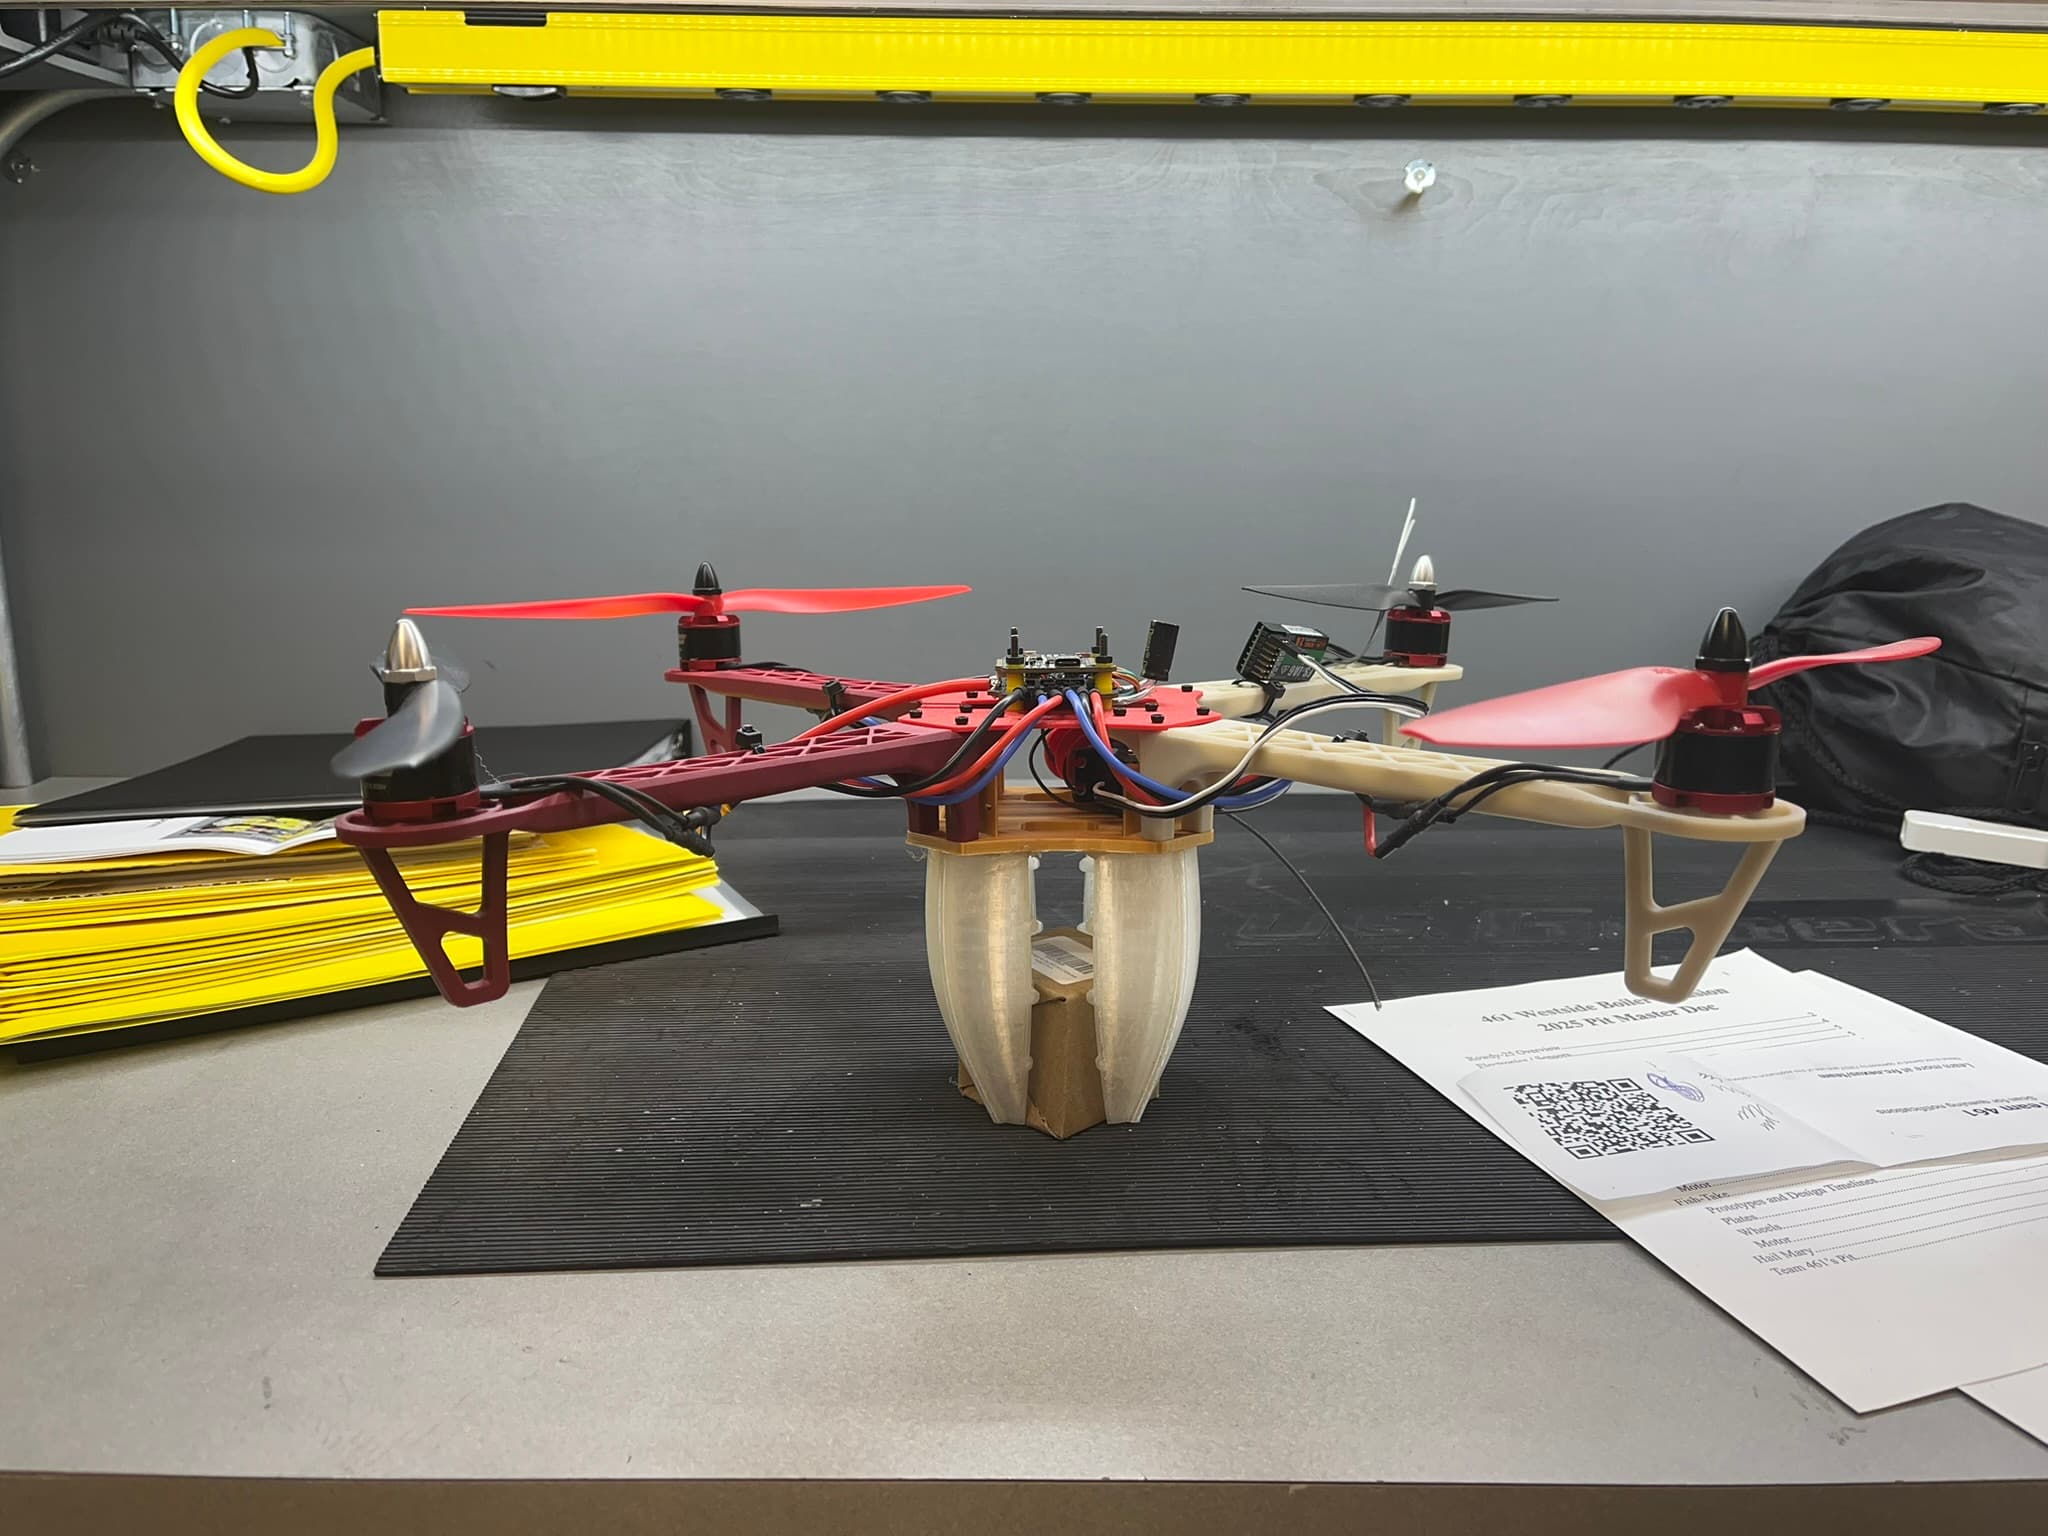
The finished Nylon-CF airframe follows the CAD architecture, integrating lattice arms, motor mounts, stacked electronics plates, landing supports, and a central gripper.